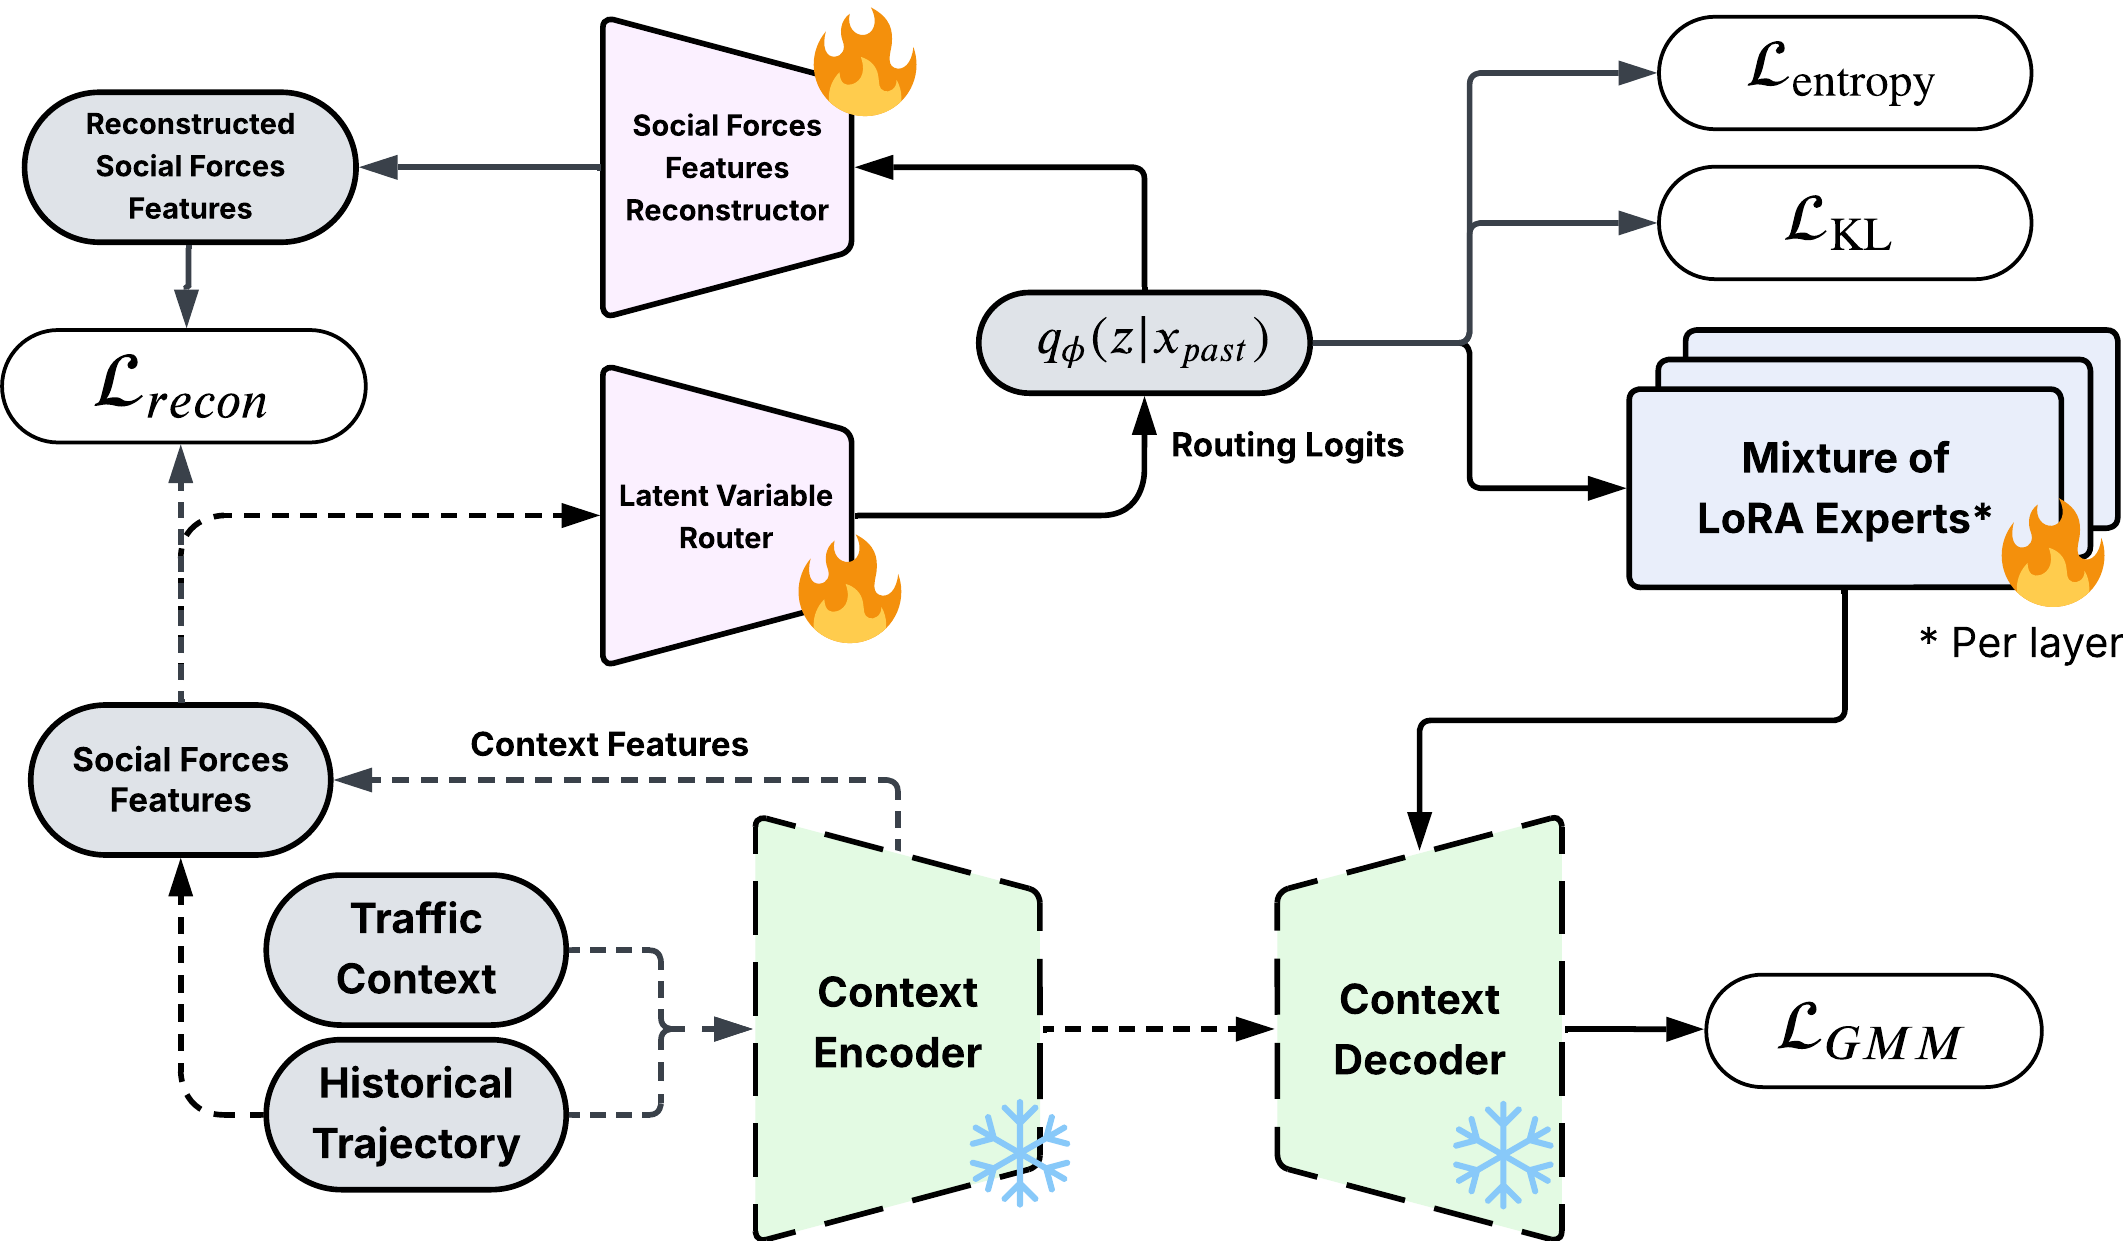
In rare but safety-critical driving scenarios, we hypothesize that trajectory outcomes become increasingly multimodal based on differences between driver style compared to non-critical, common scenarios. However, current approaches for trajectory prediction rarely account for differences in driving style, which may lead to "averaged" driving style in predictions. While average-case behavior may work well in straight driving, easy scenarios, it limits the diversity of outcomes in more complex scenes or in rare events. Extraction of driving style has several benefits, as it enables simulation of counterfactual outcomes in real-world log replays and potentially more accurate predictions through style-consistent predictions. In this paper, we present Polysona, a parameter-efficient Mixture-of-Experts framework for extraction of latent driving styles in trajectory prediction models. We choose a parameter-efficient approach to reduce forgetting in well-generalized trajectory prediction models, while offering portability of trained driving style modules. In our results, we benchmark different mixture-of-LoRA approaches with our method and provide qualitative analysis on how the learned experts specialize.
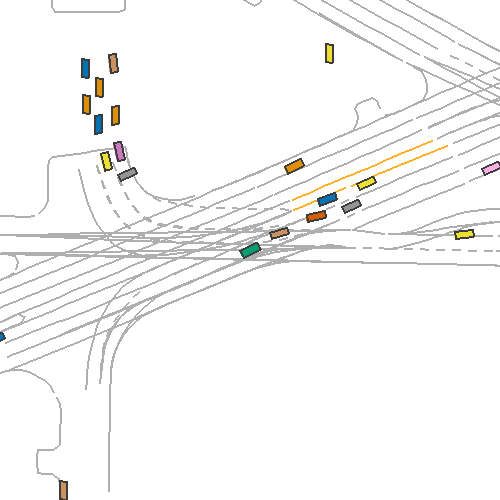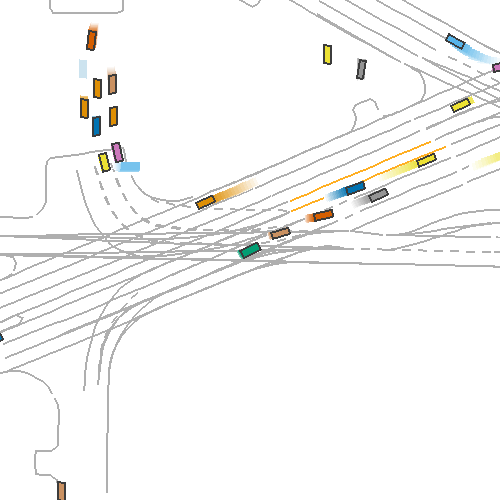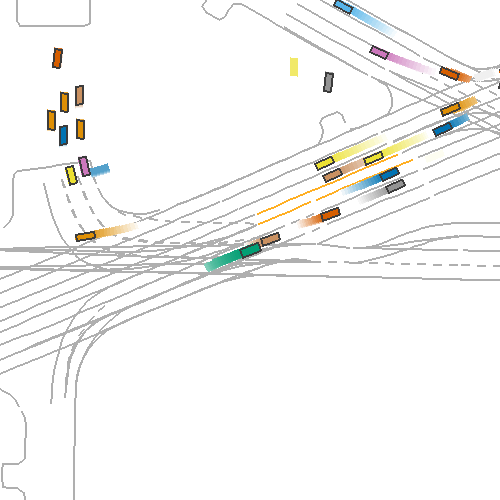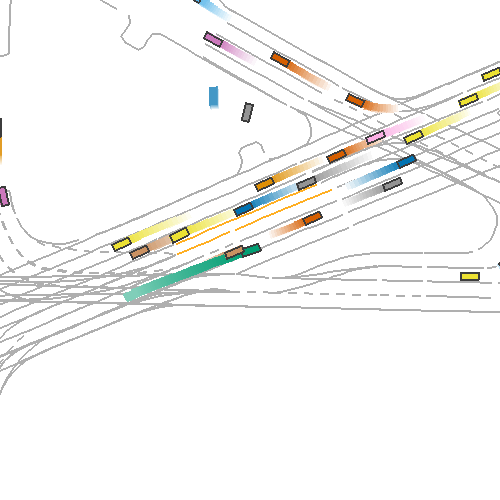
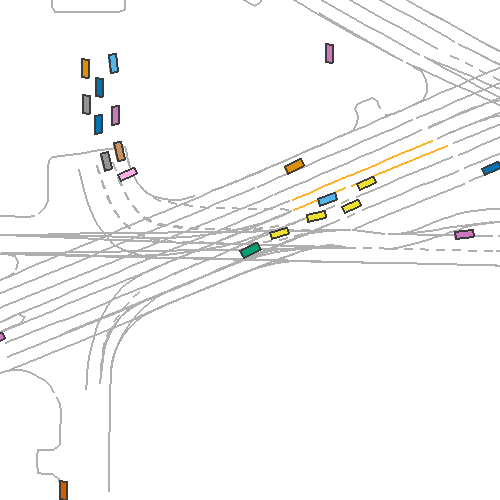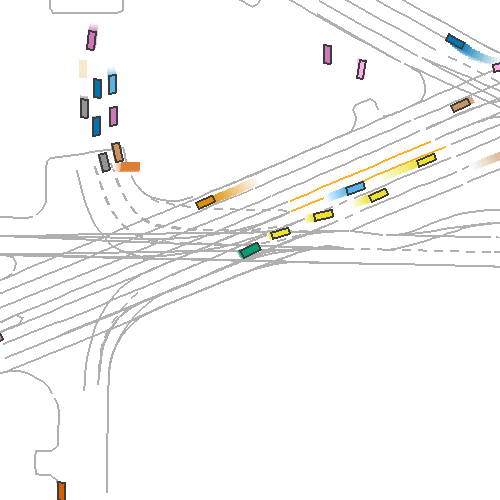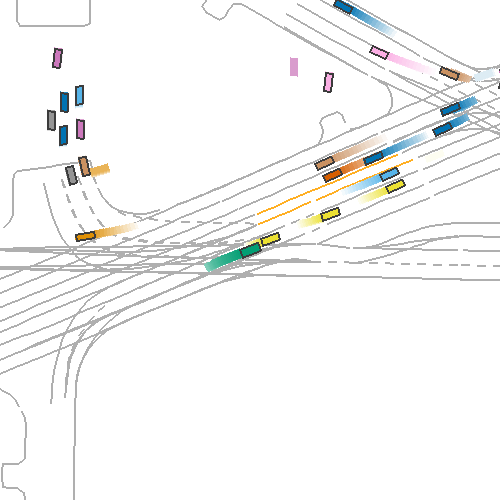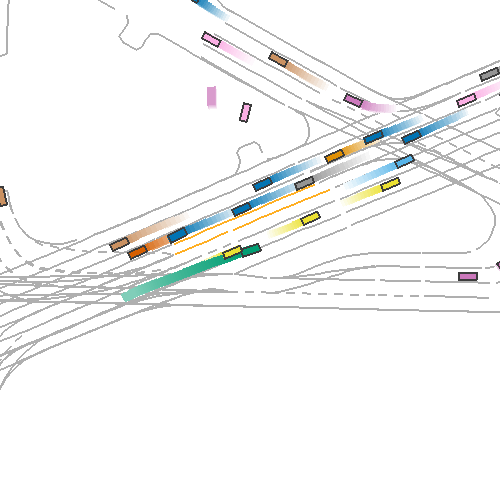
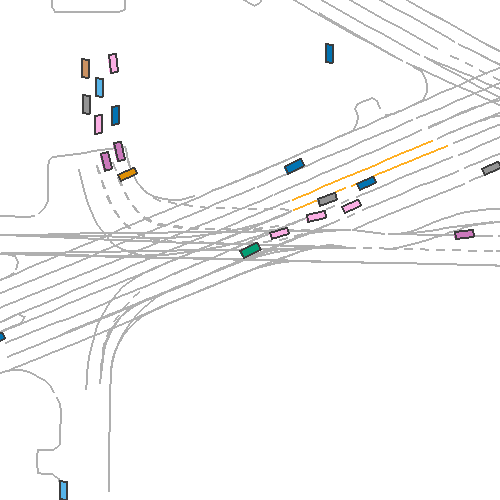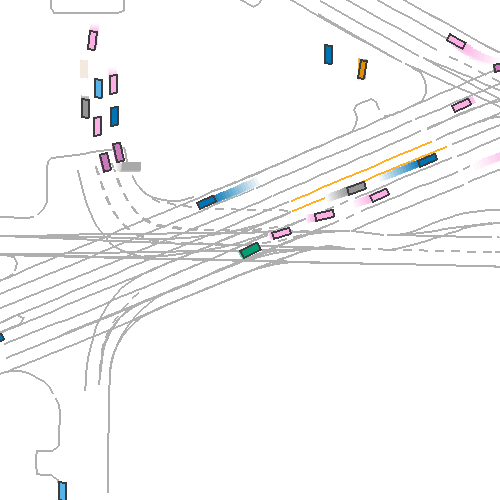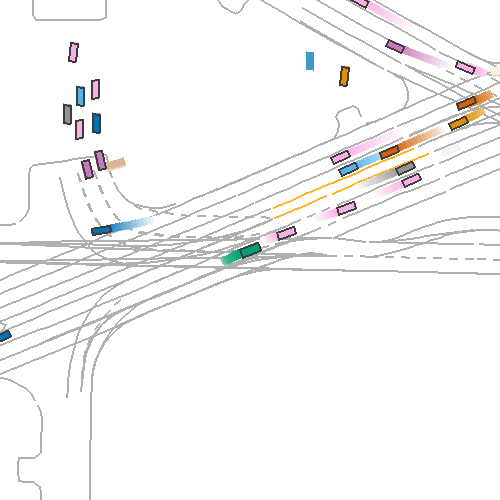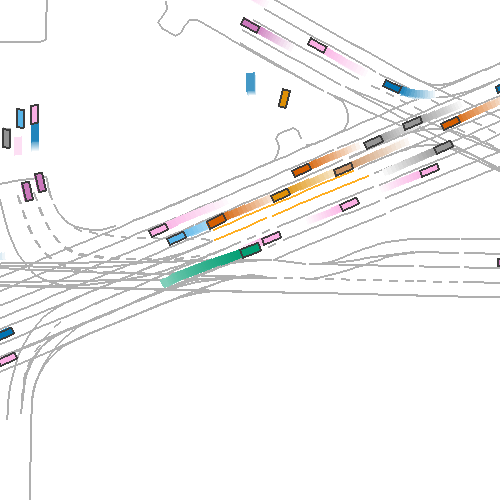
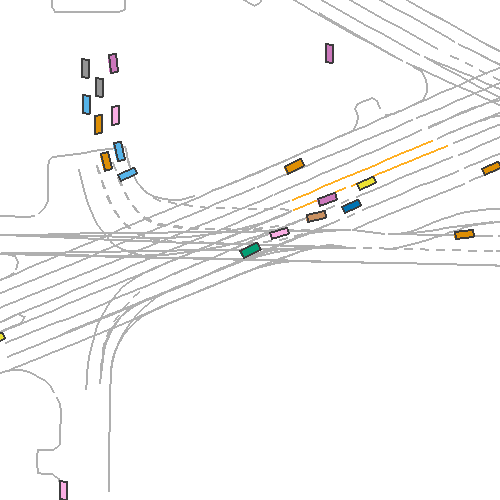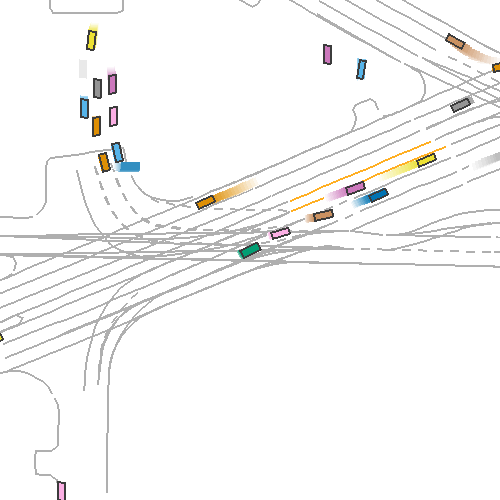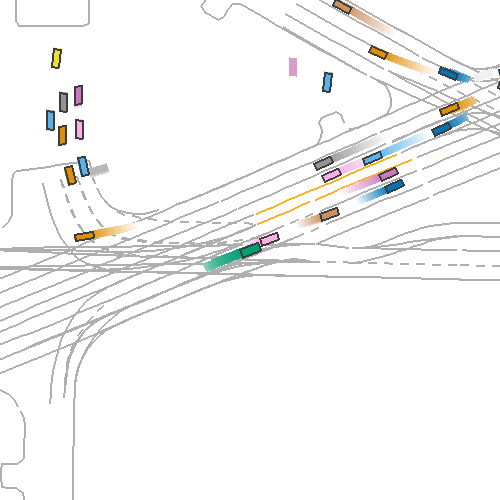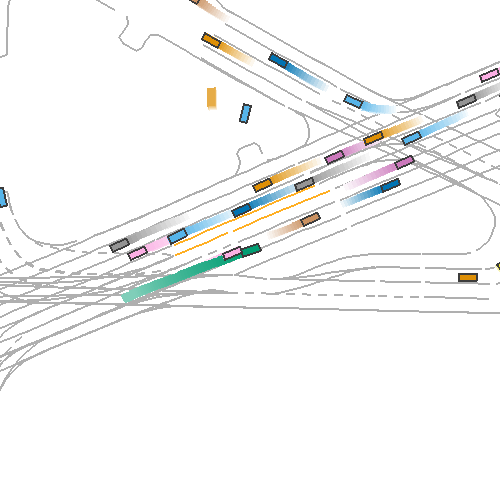
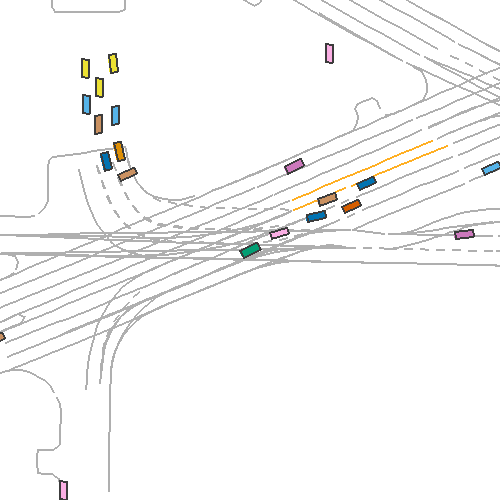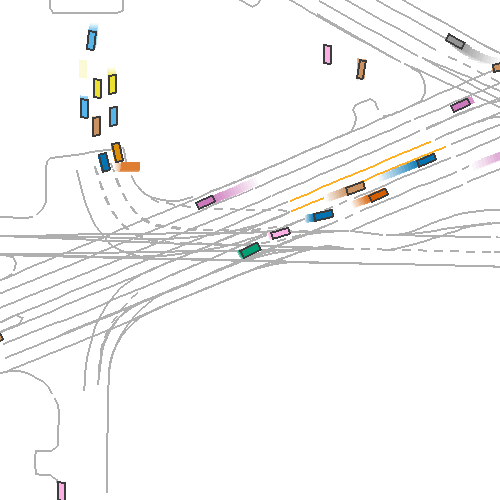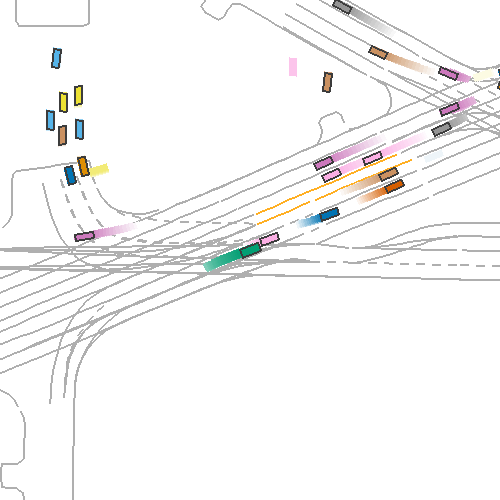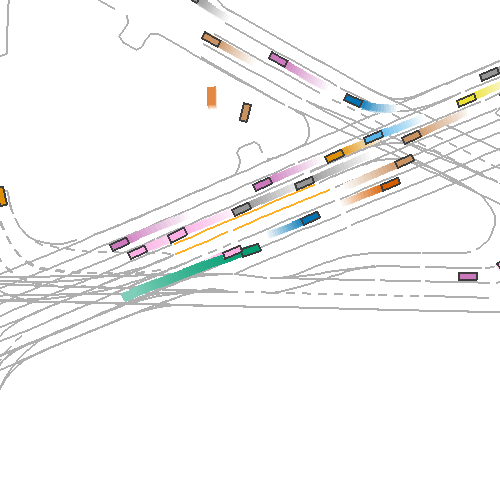
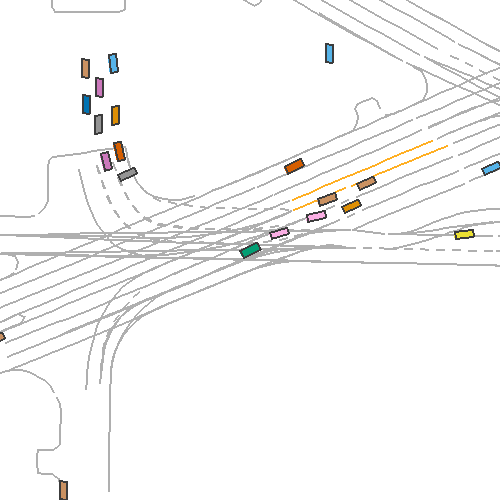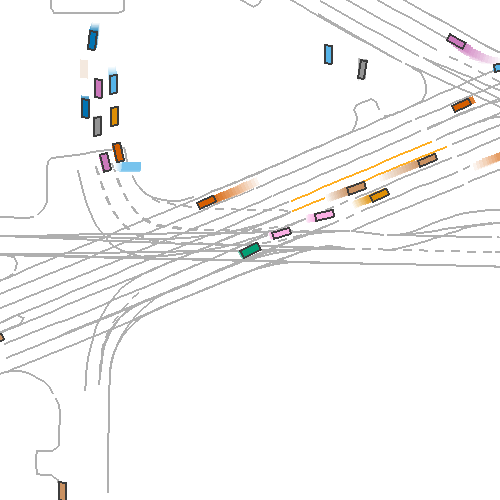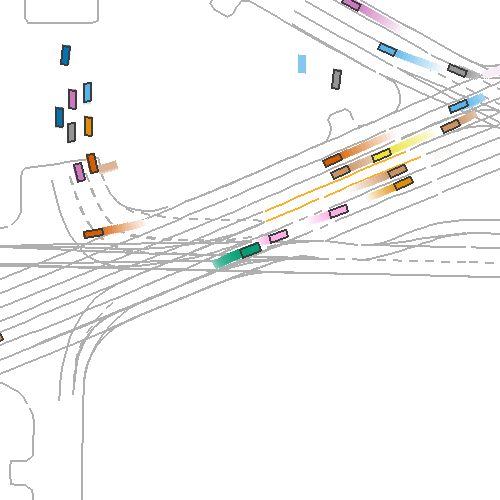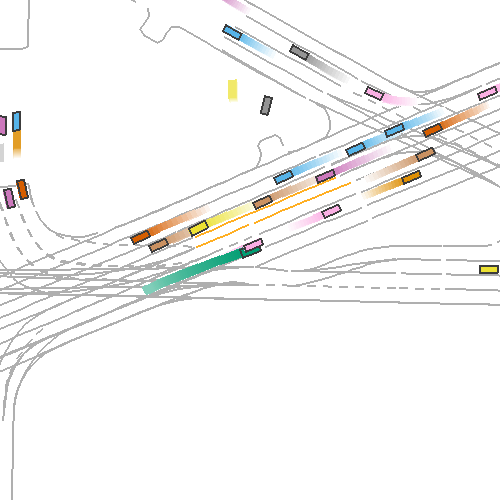
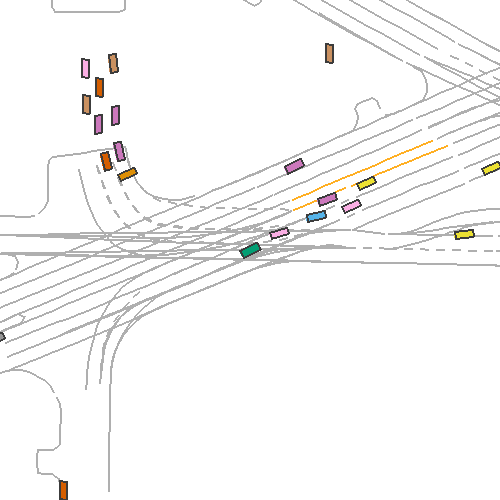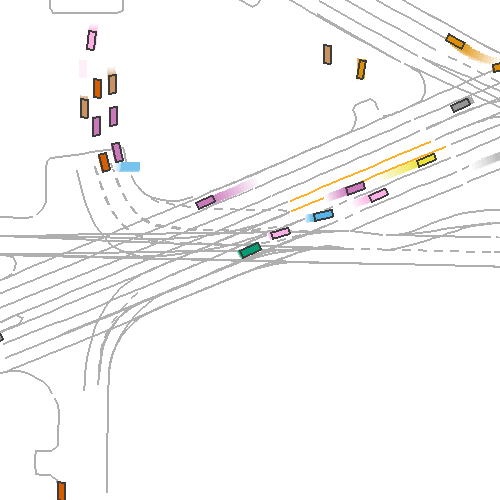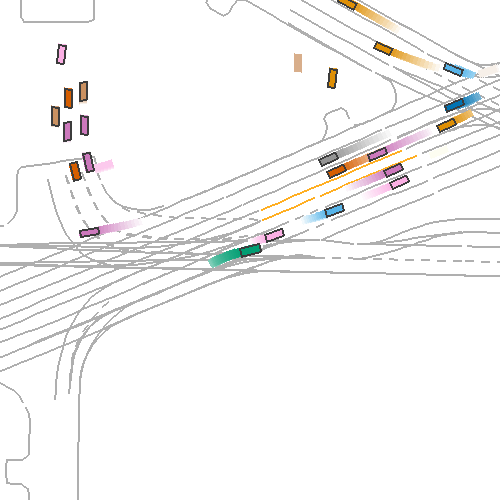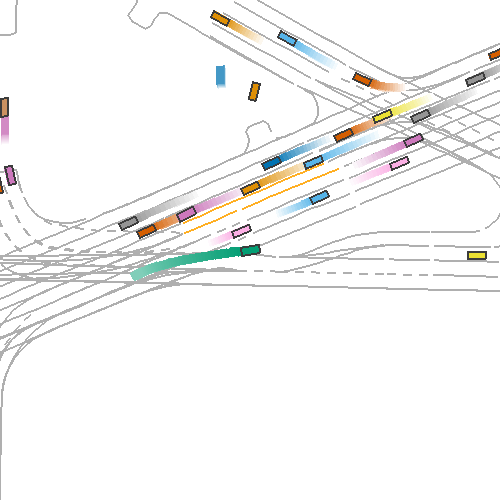
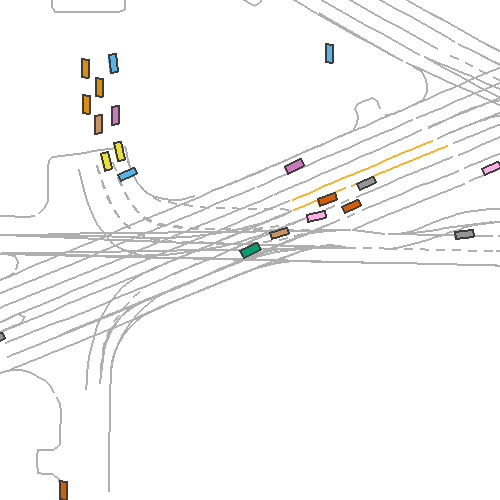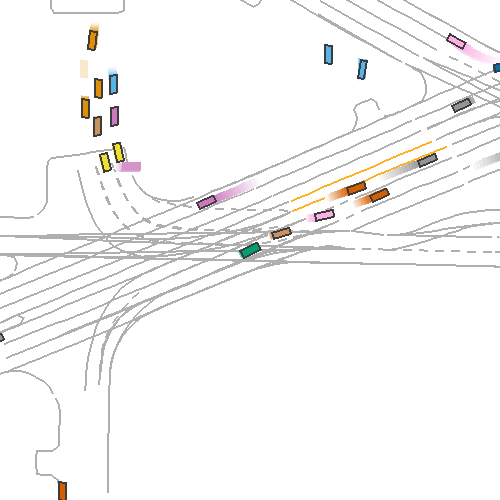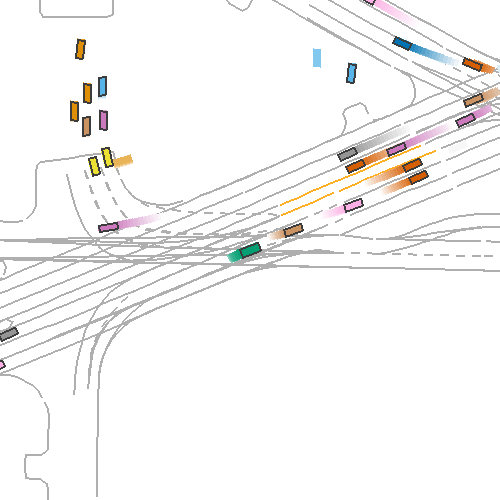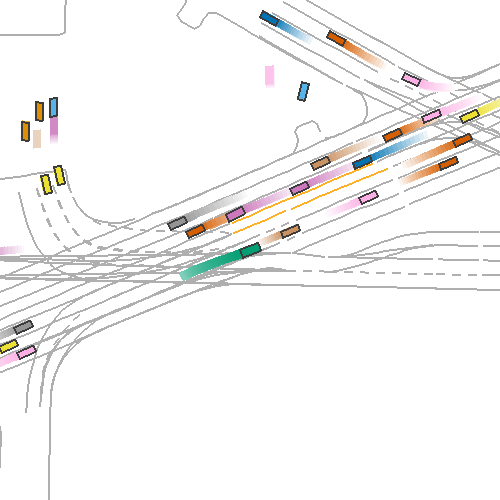
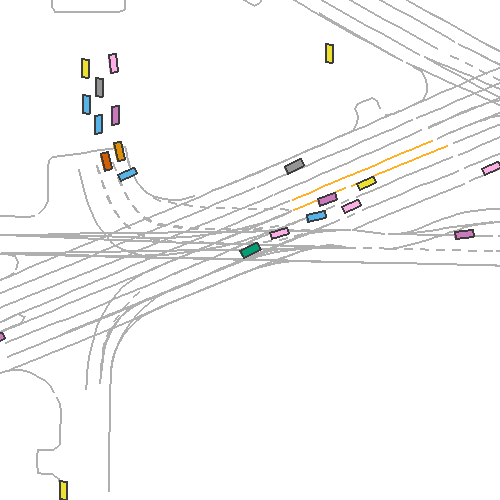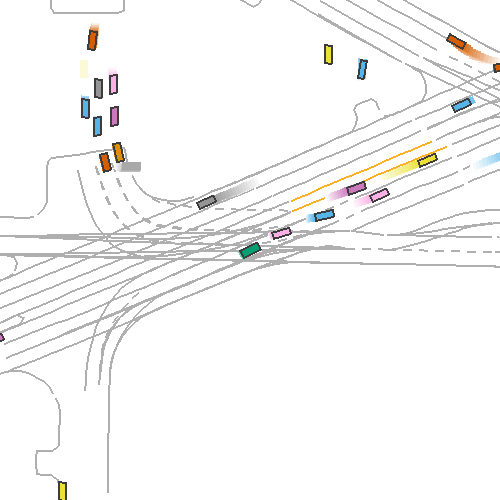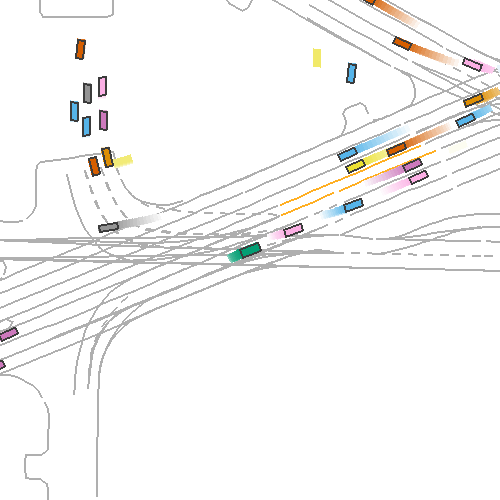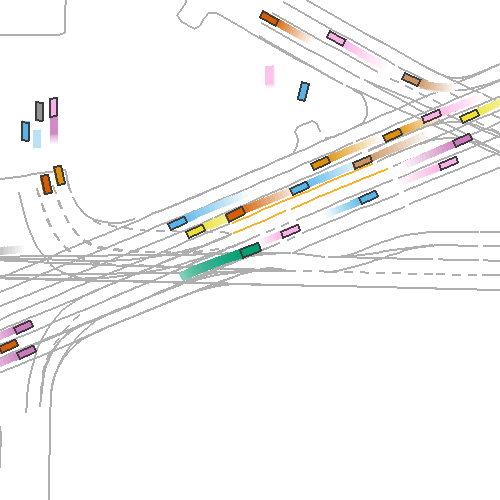
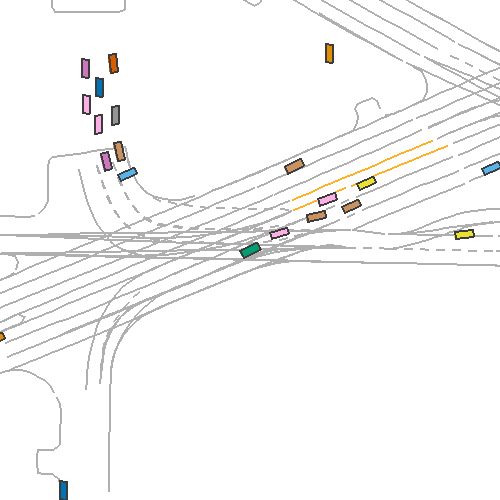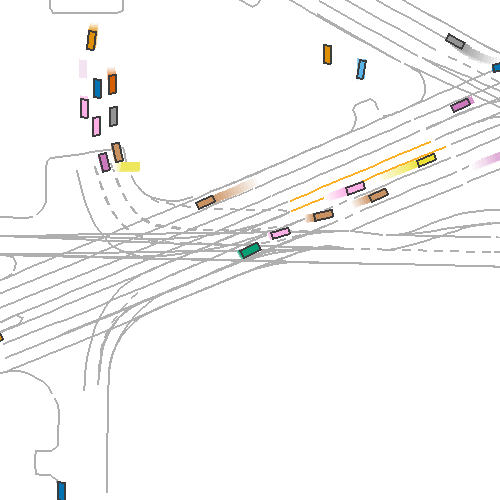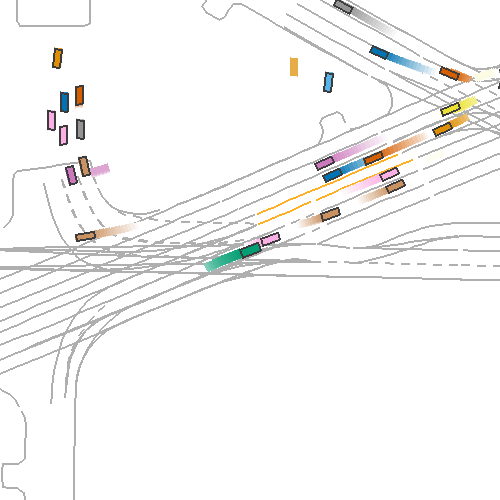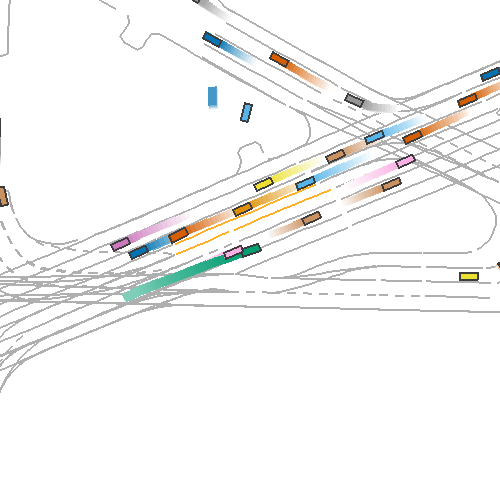
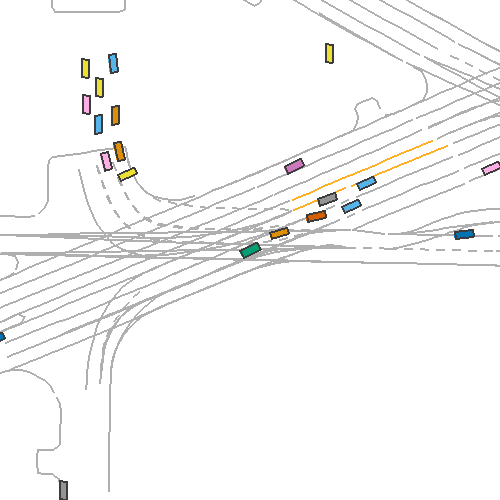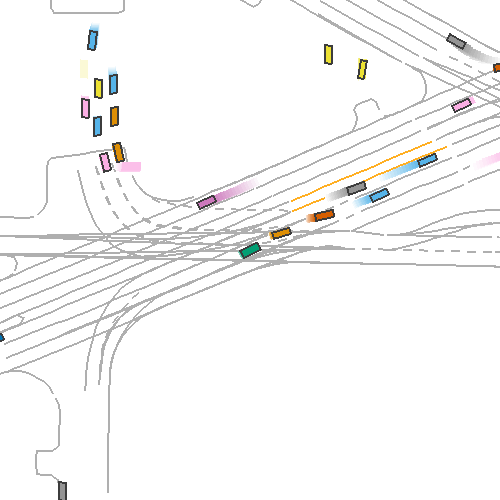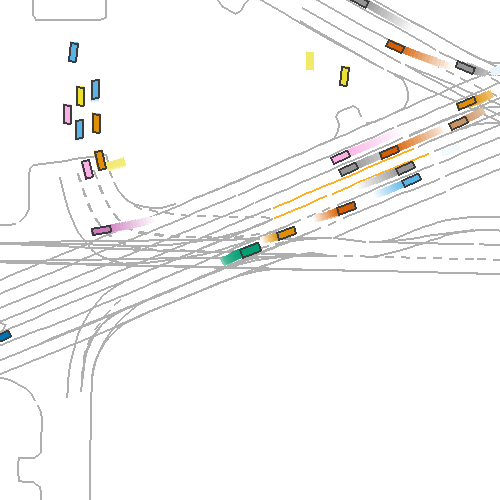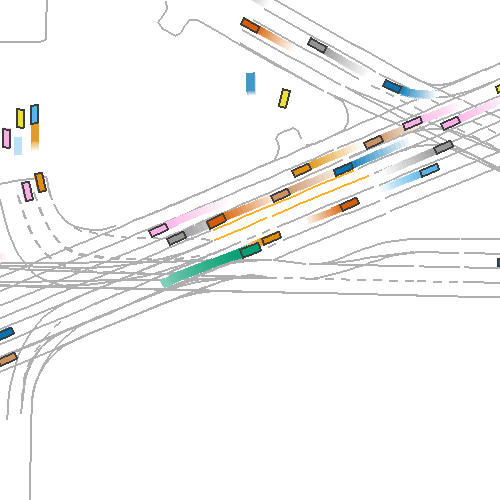
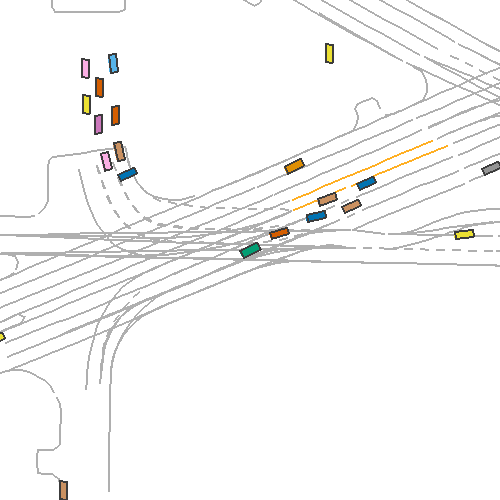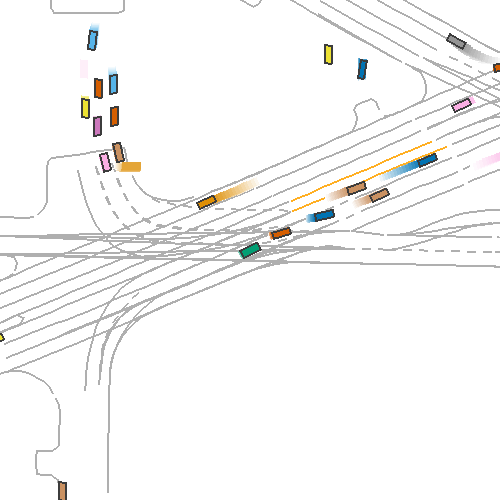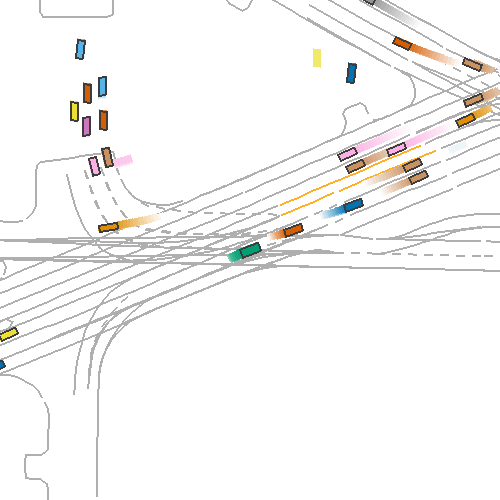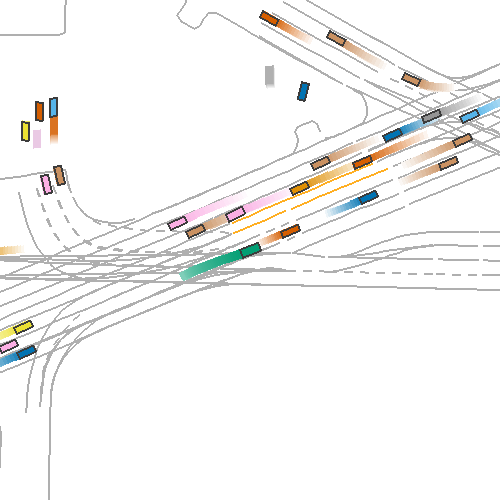
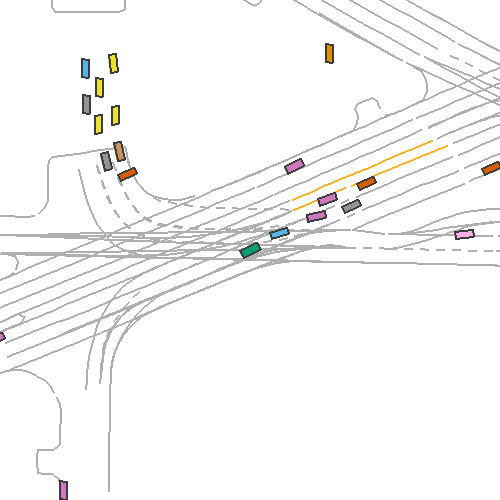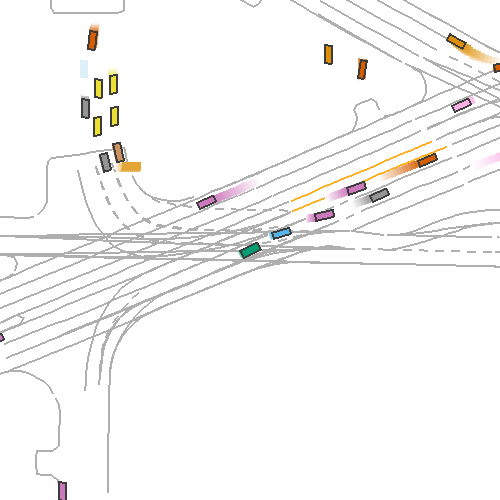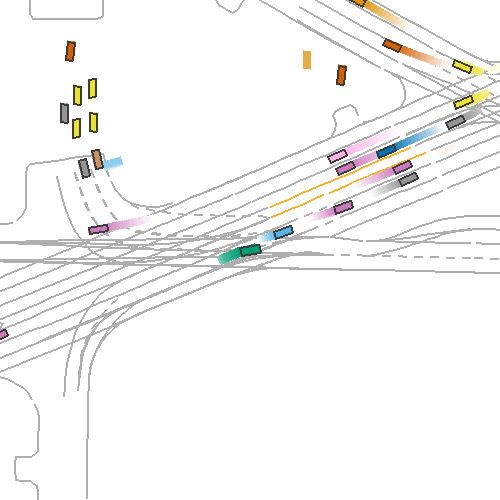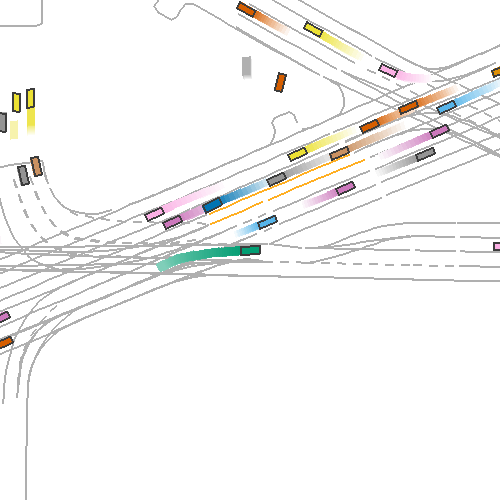
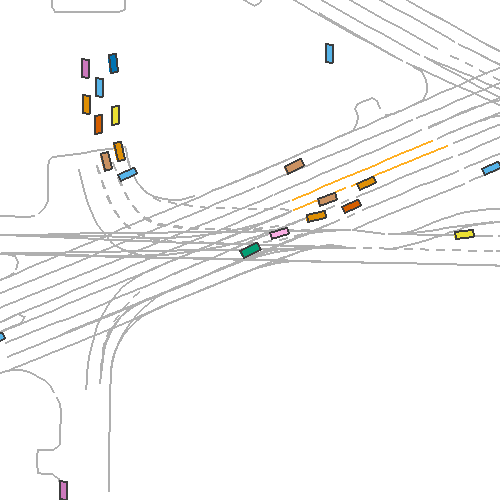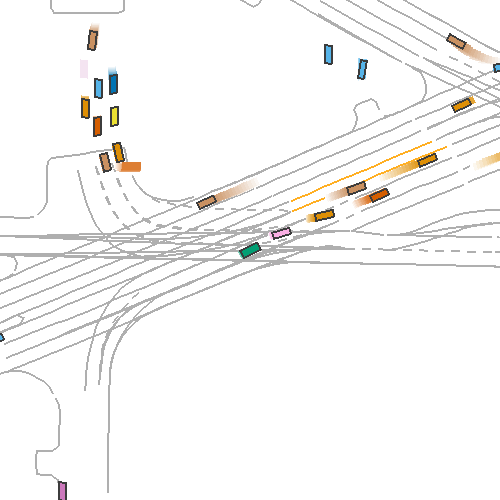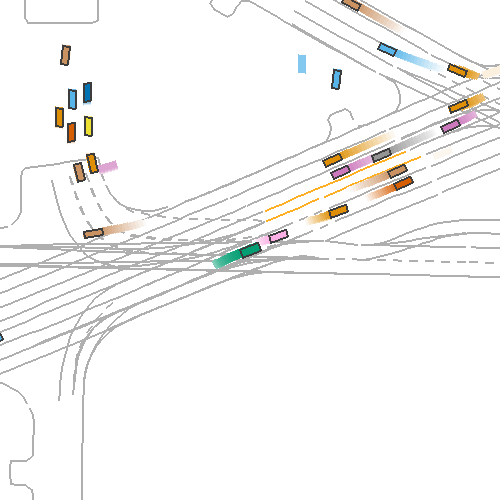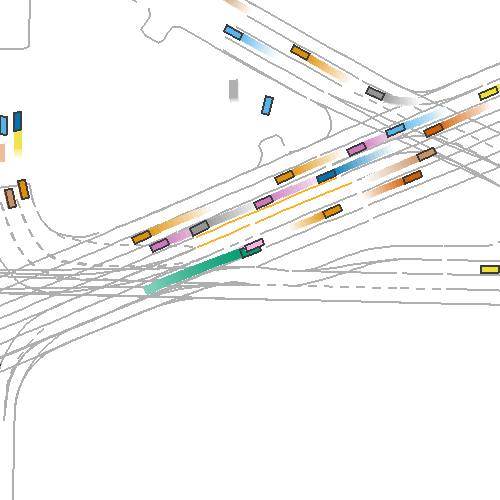
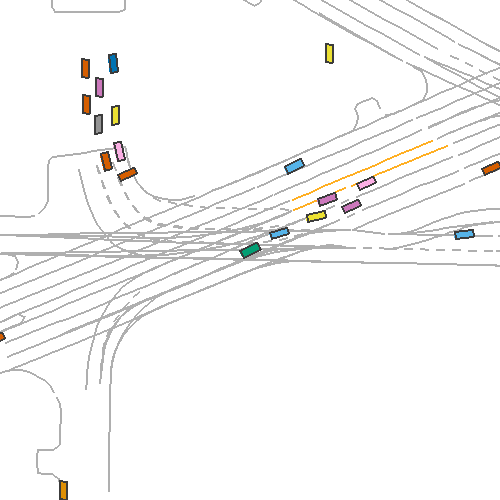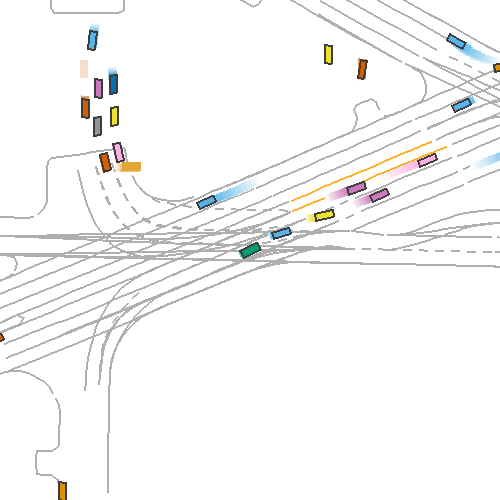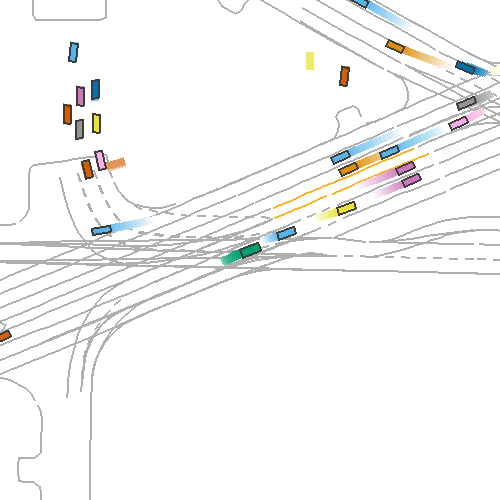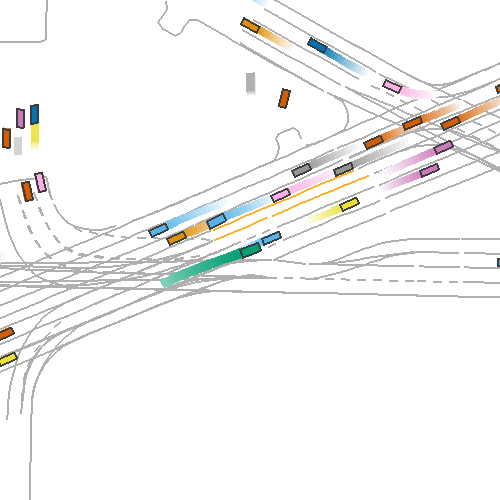
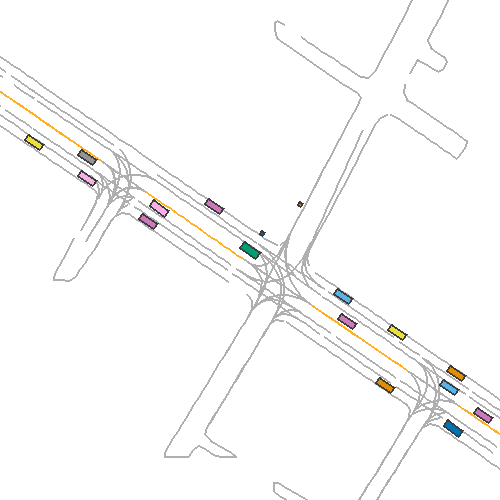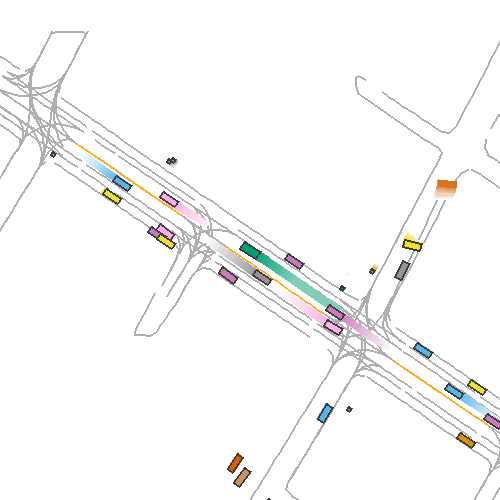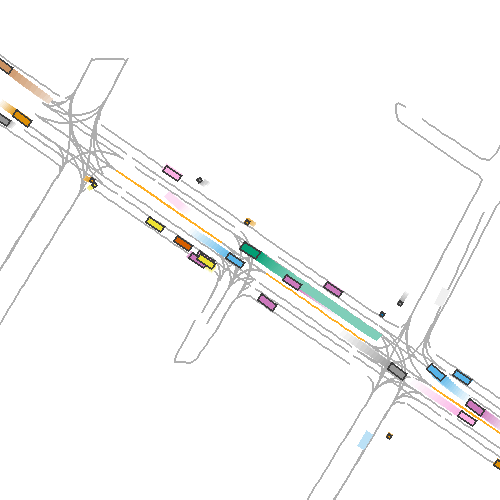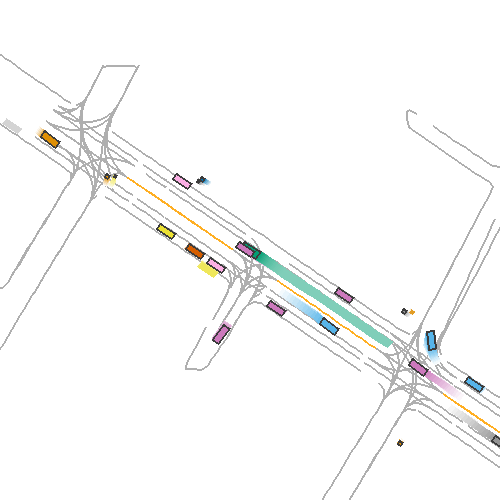
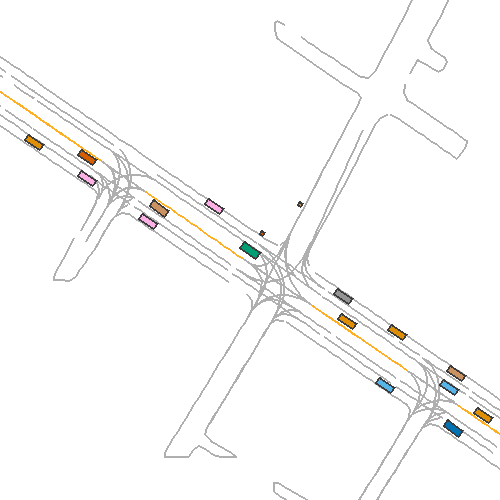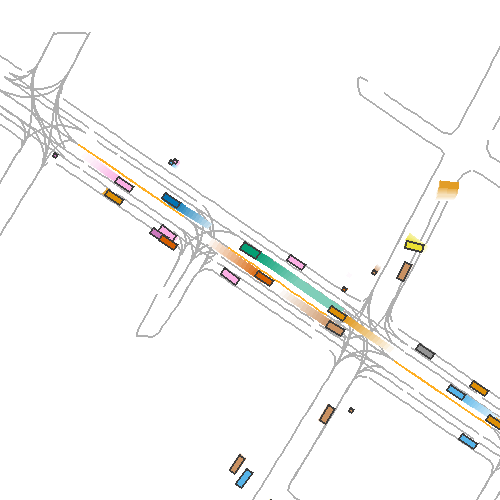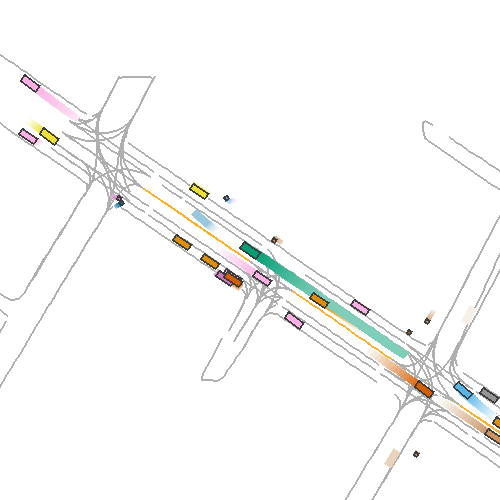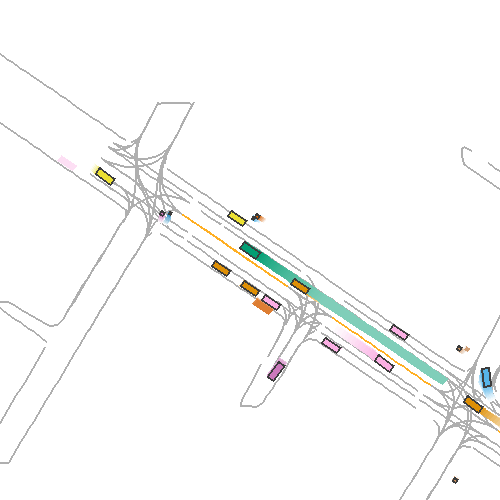
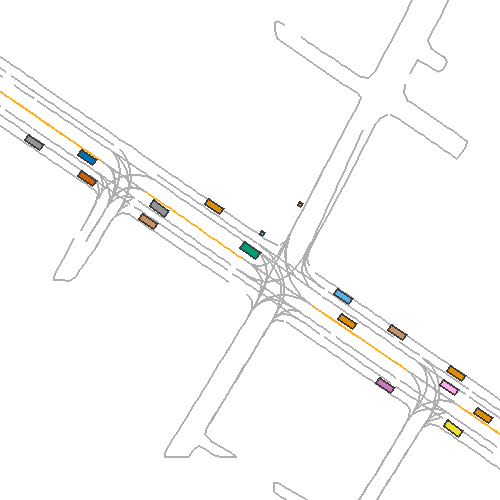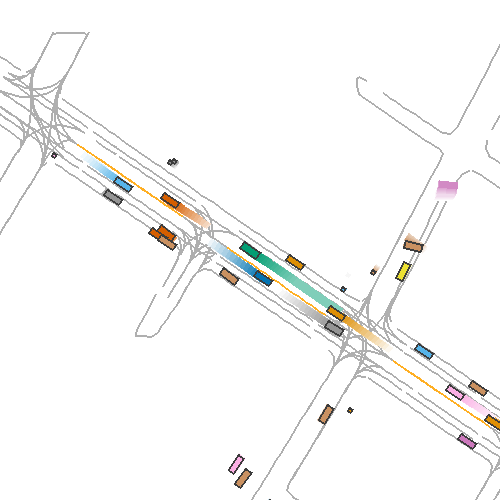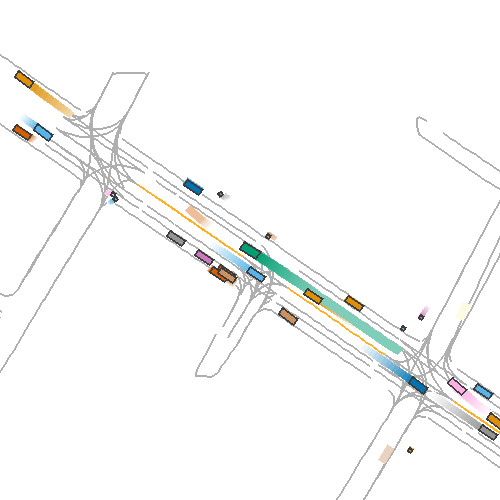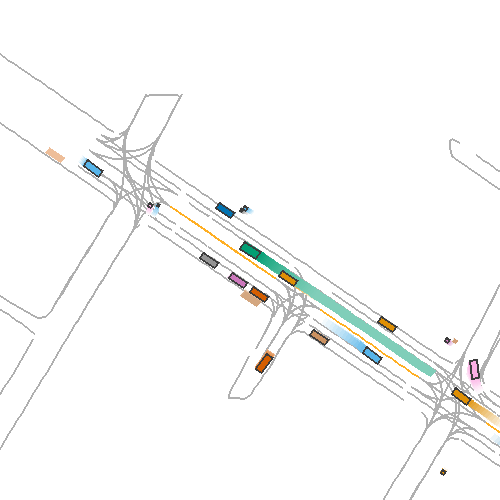
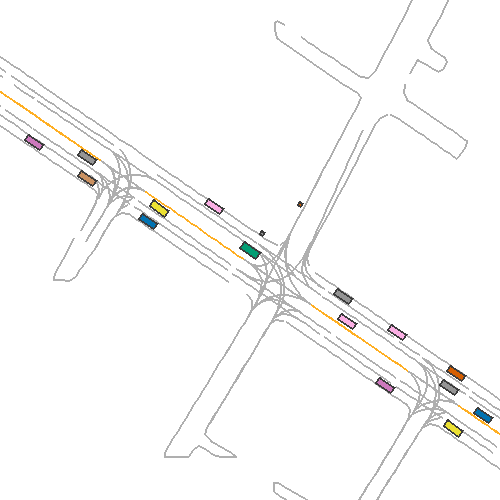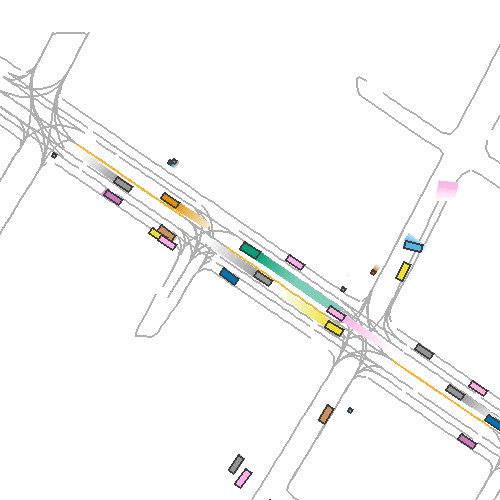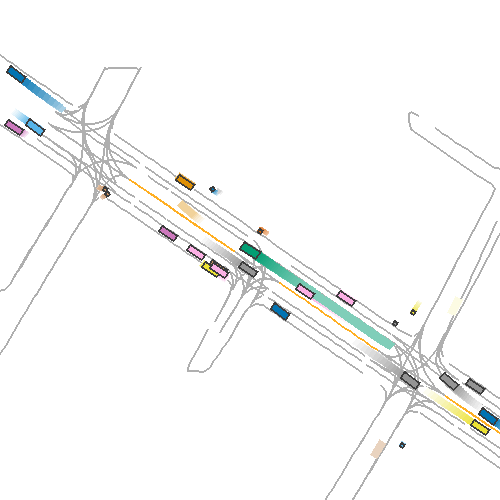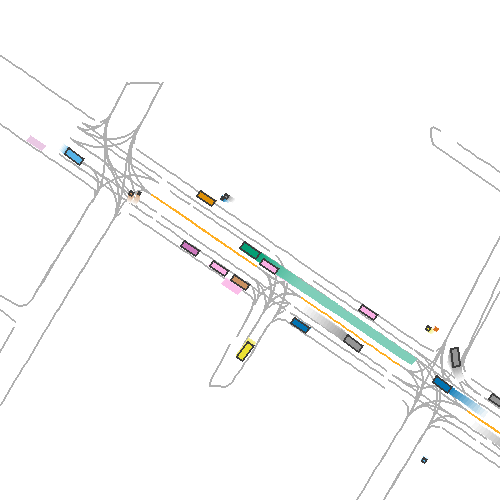
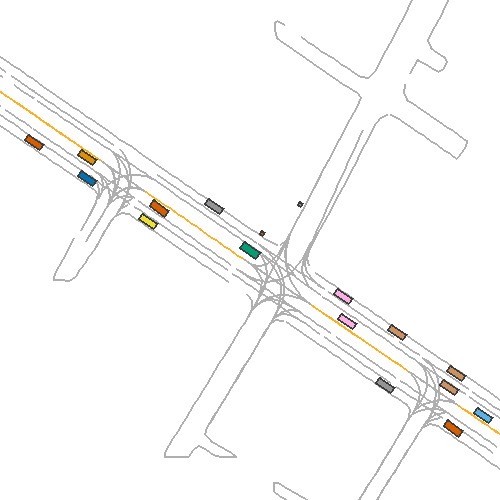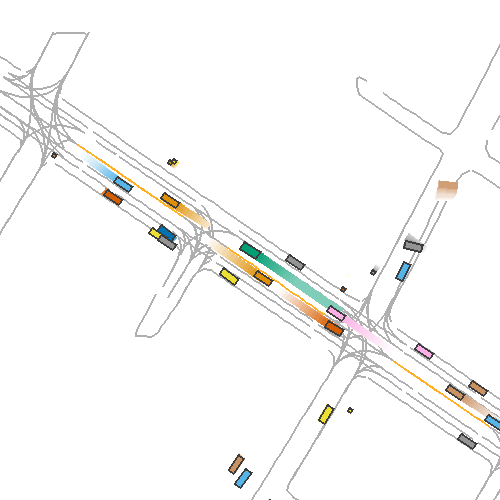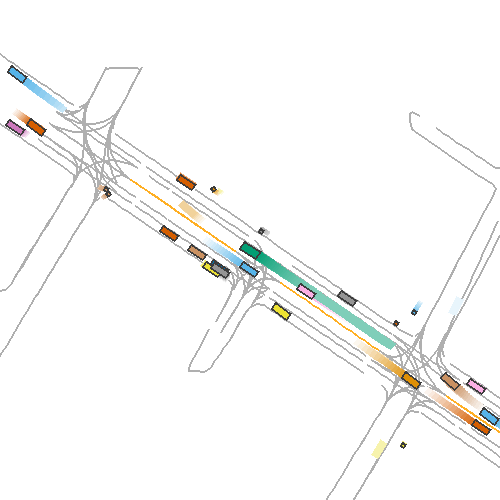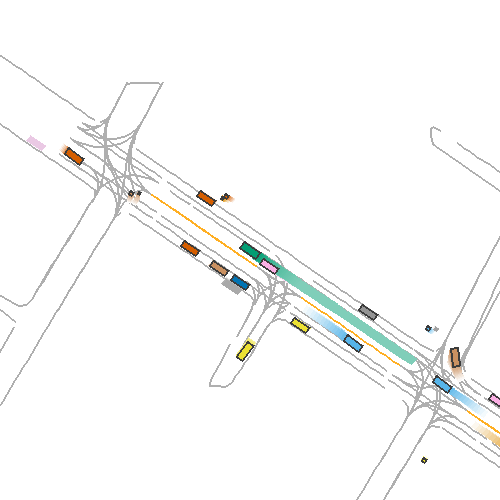
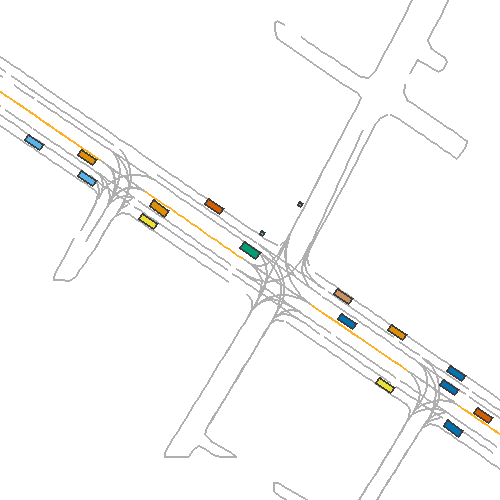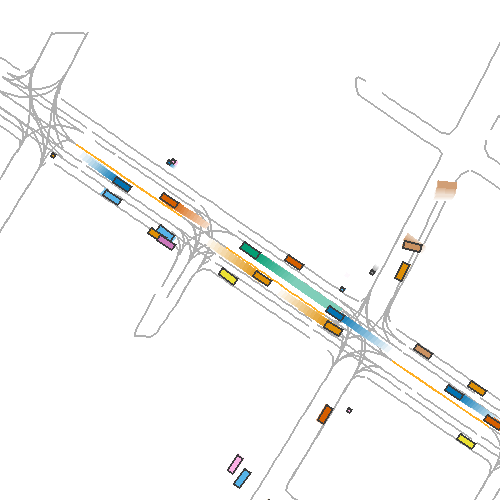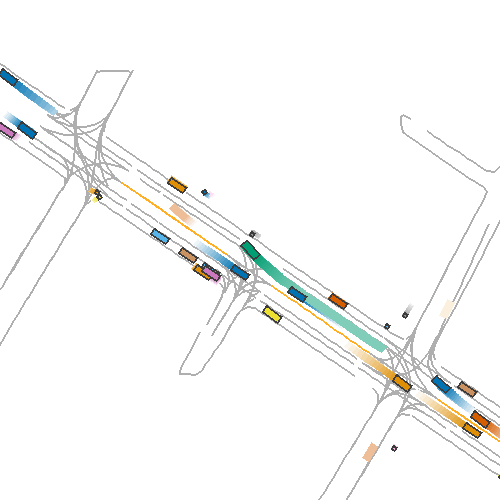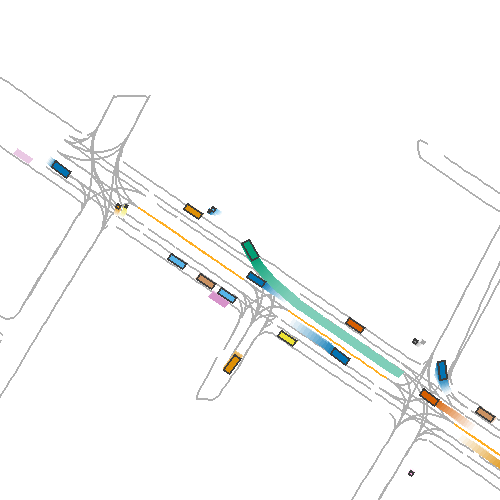
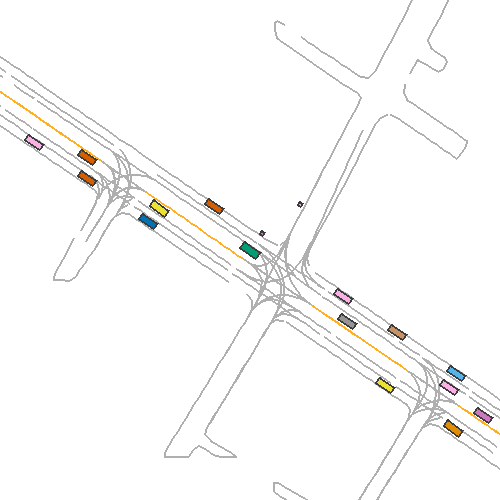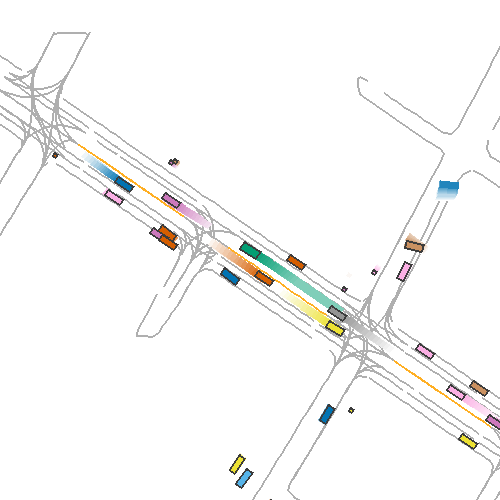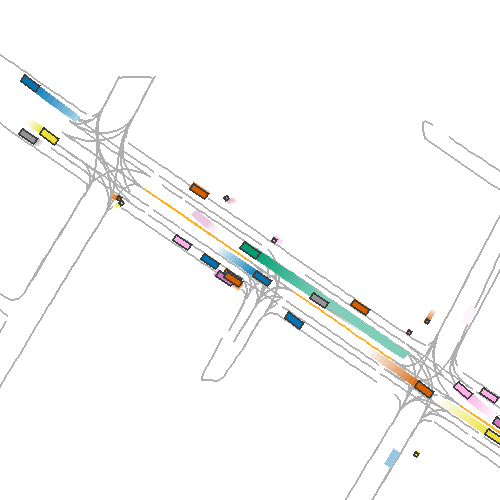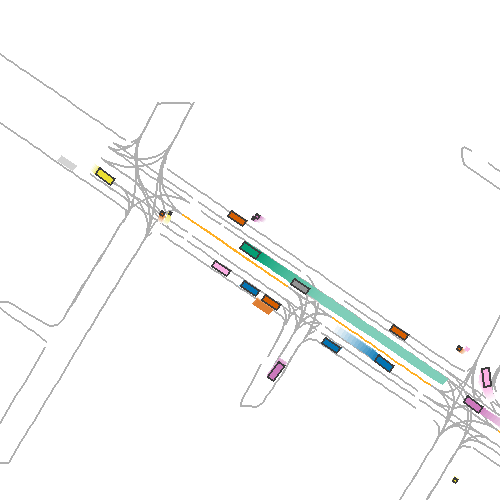
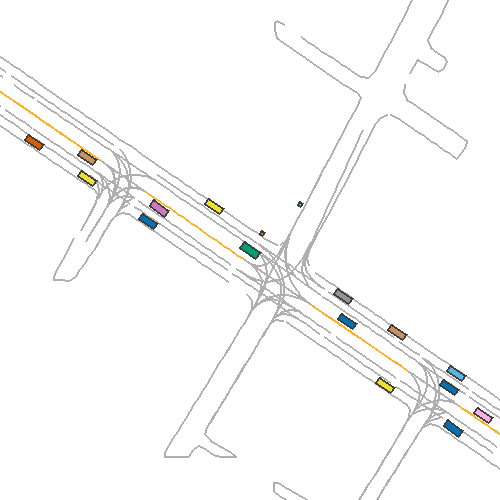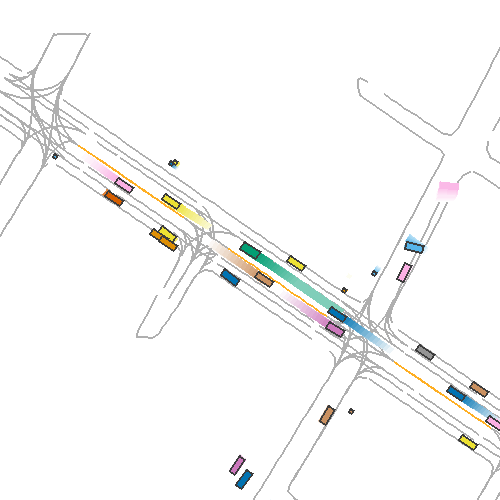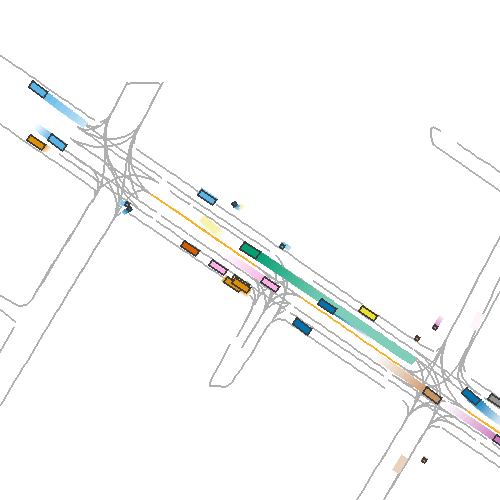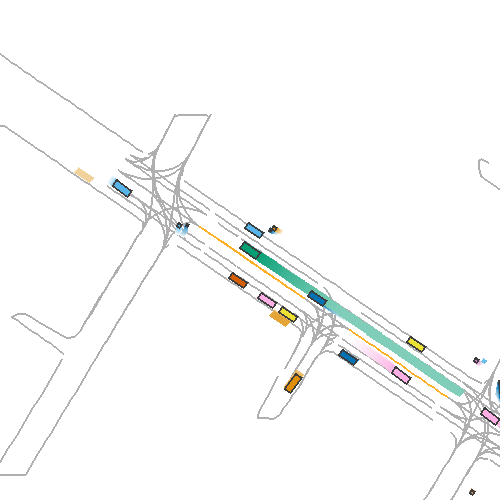
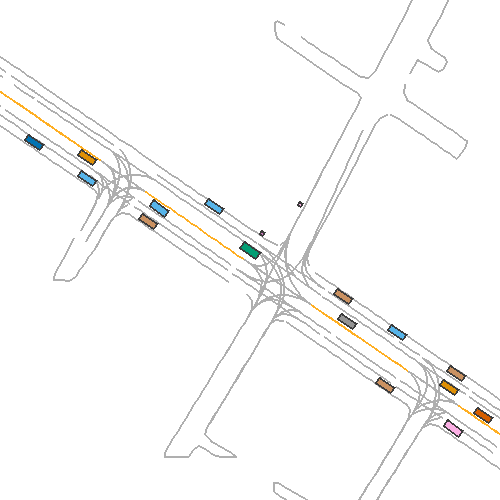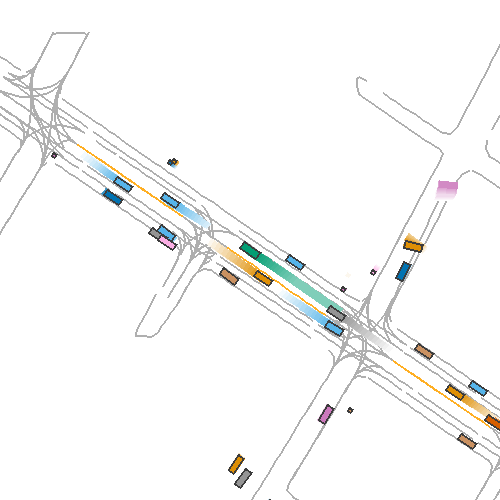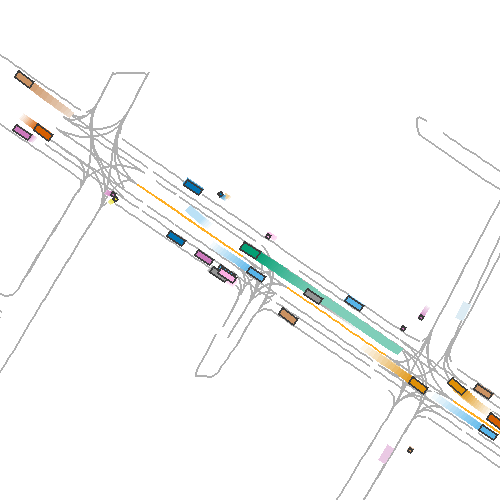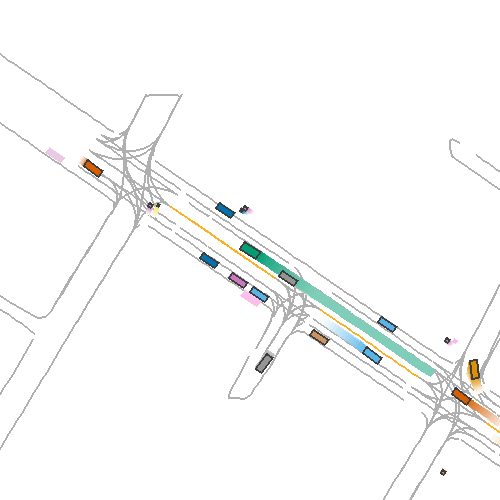
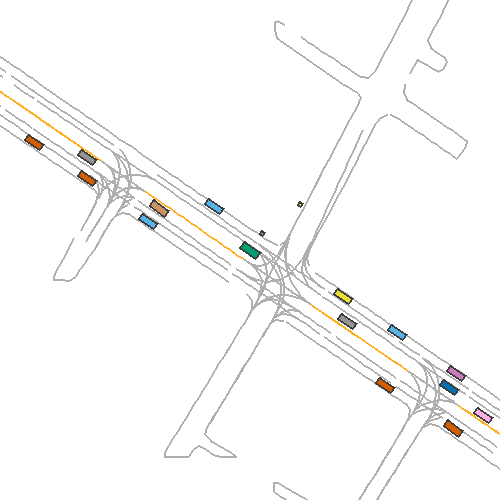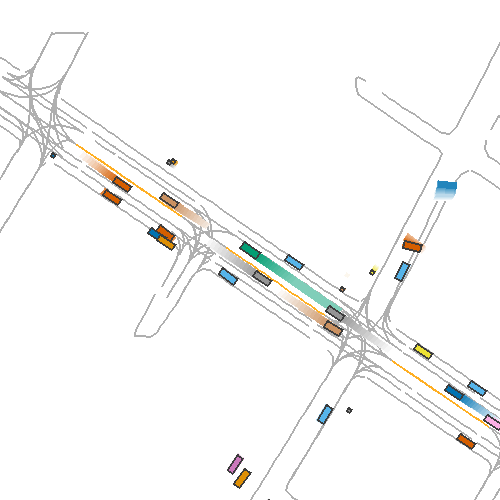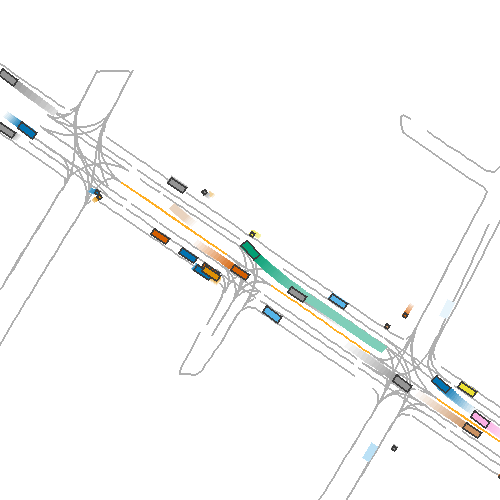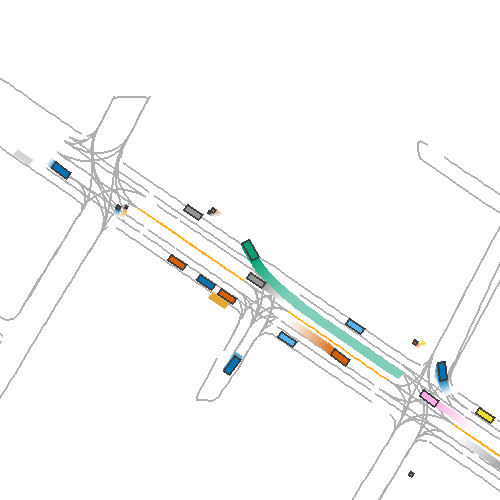
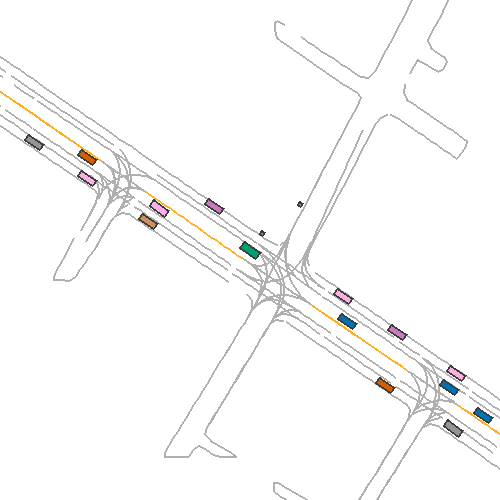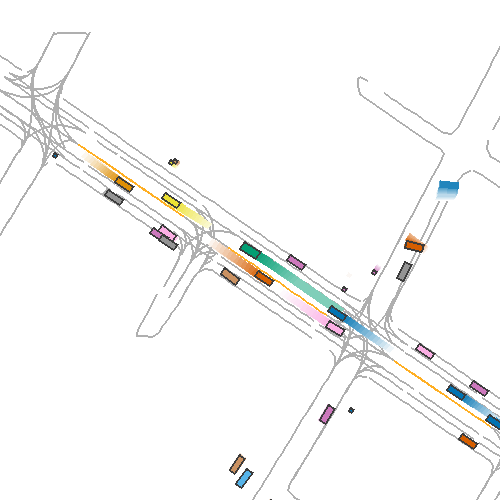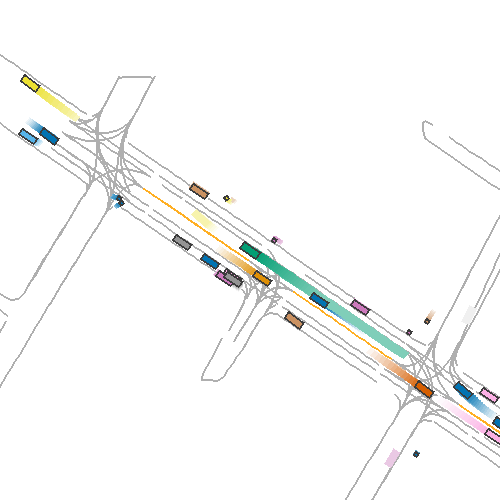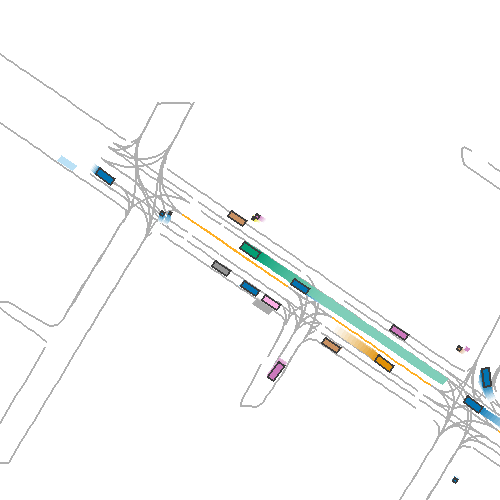
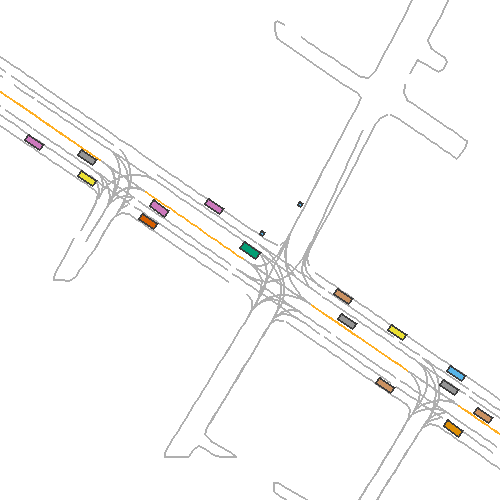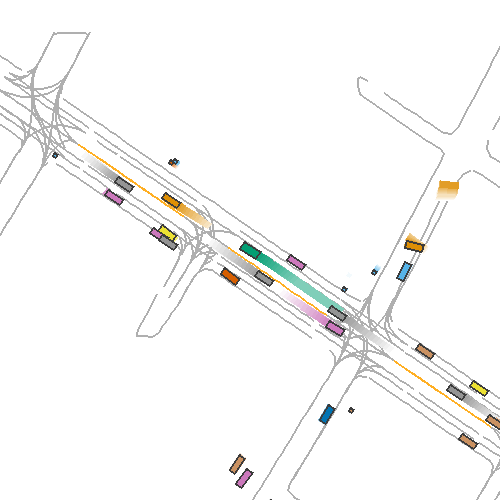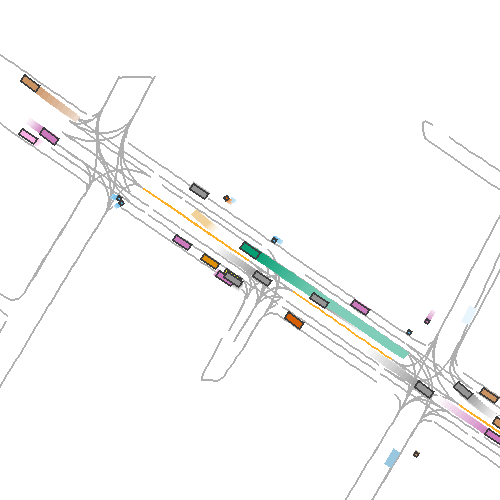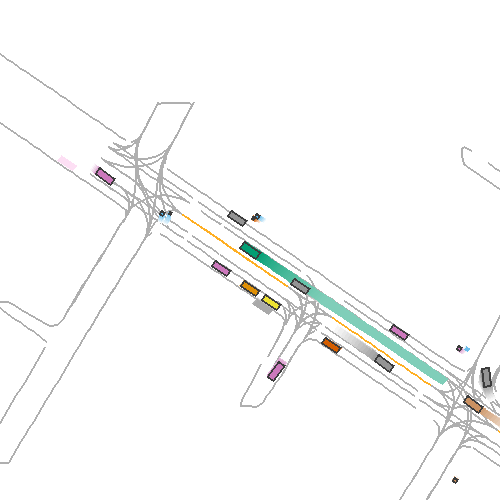
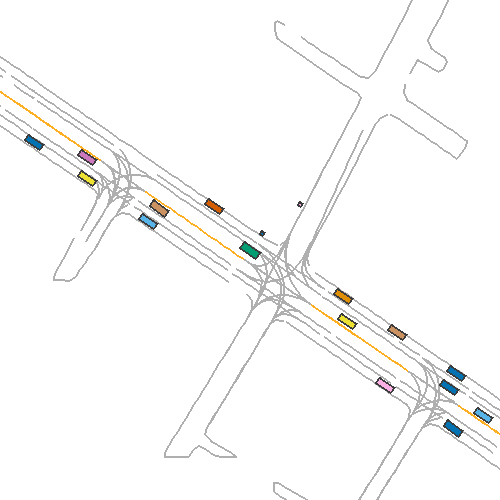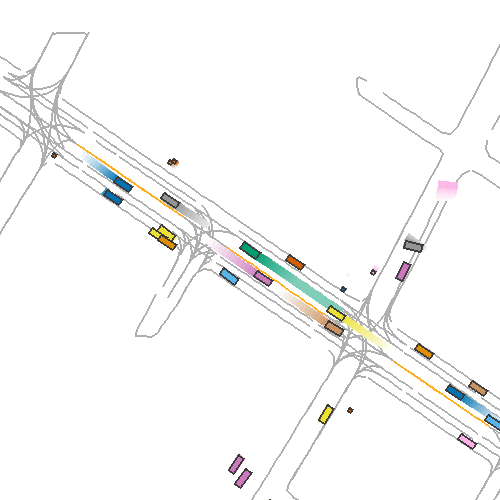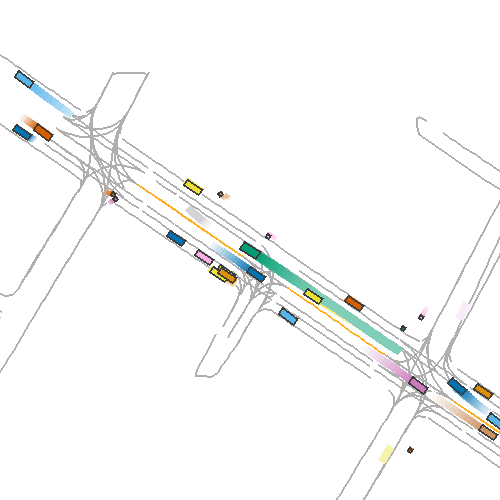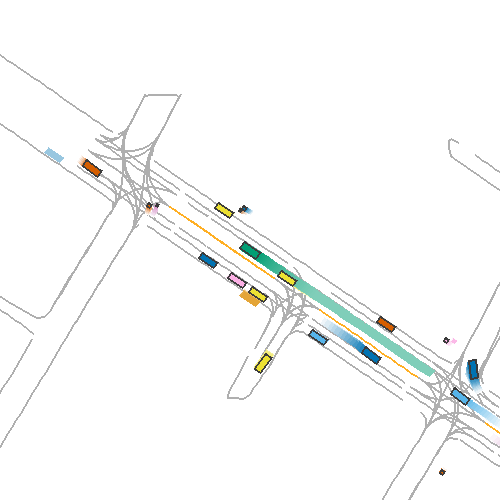
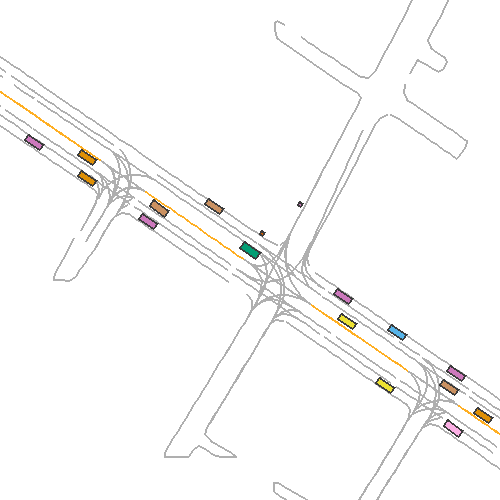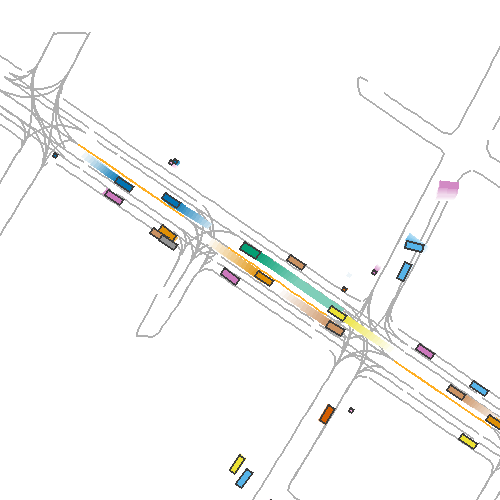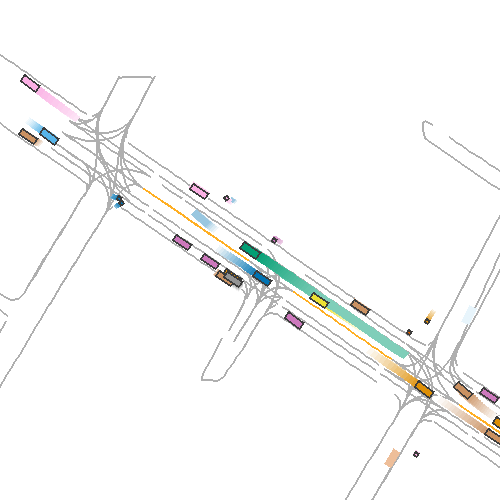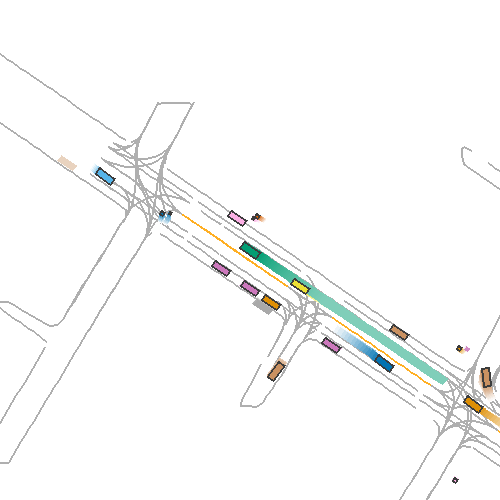
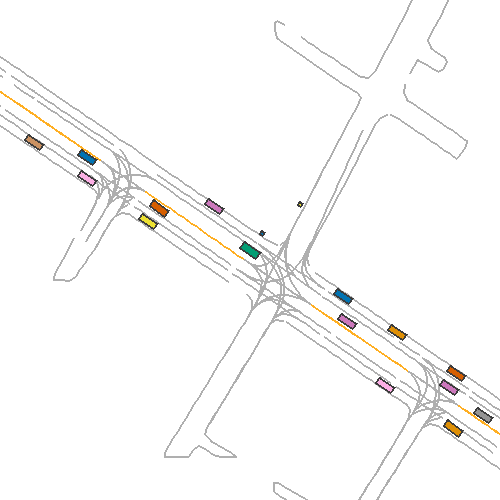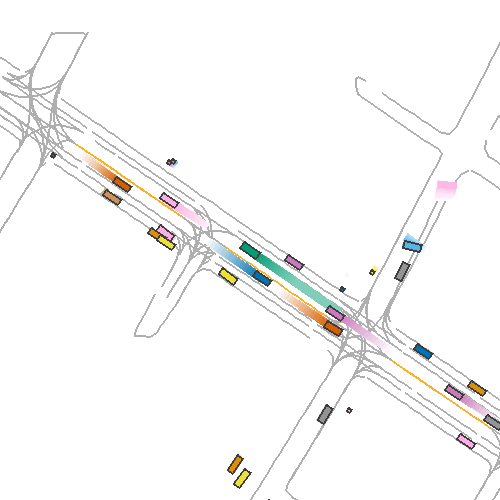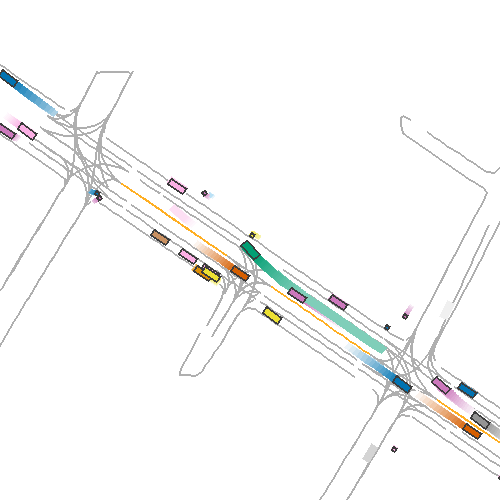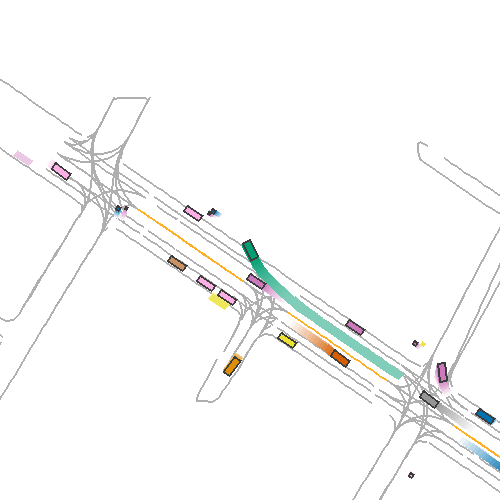
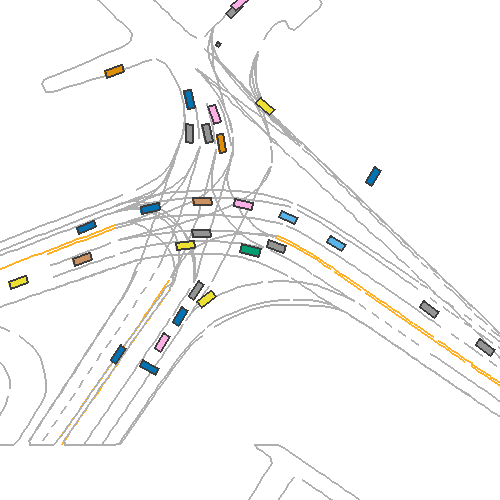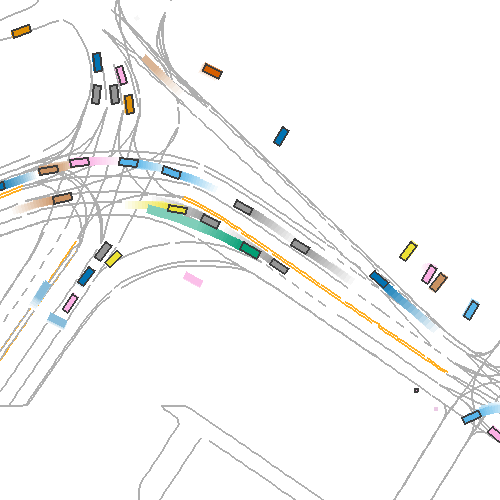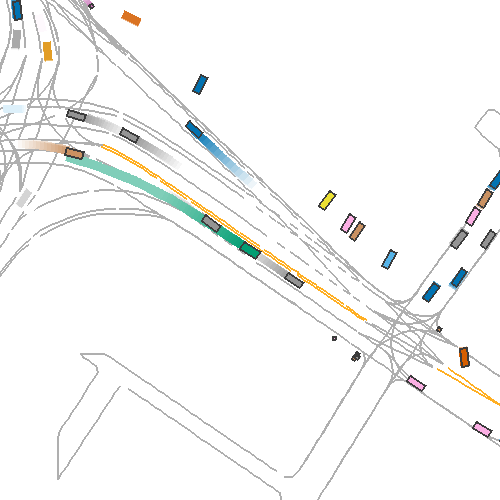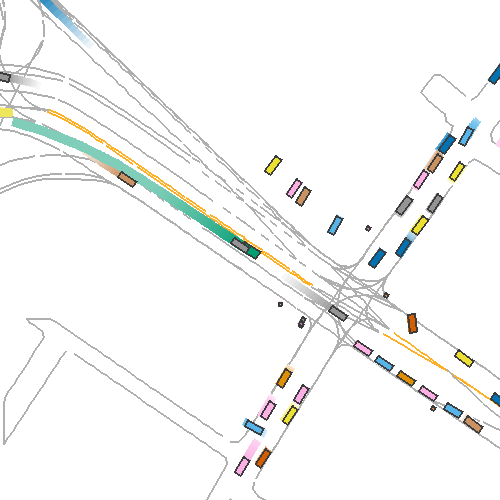
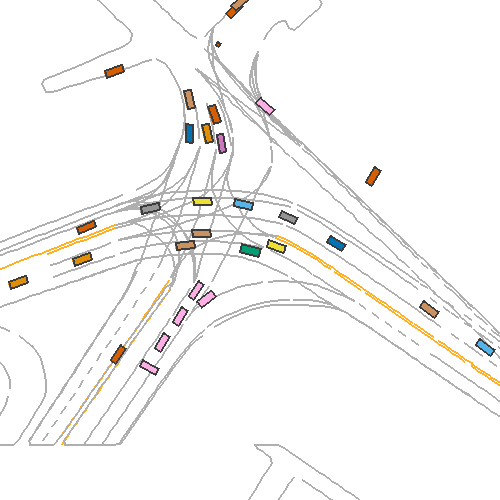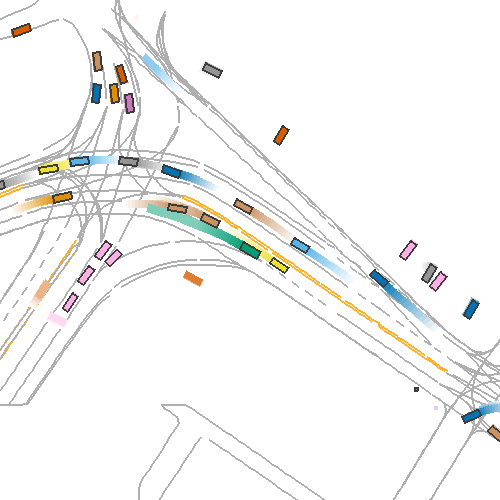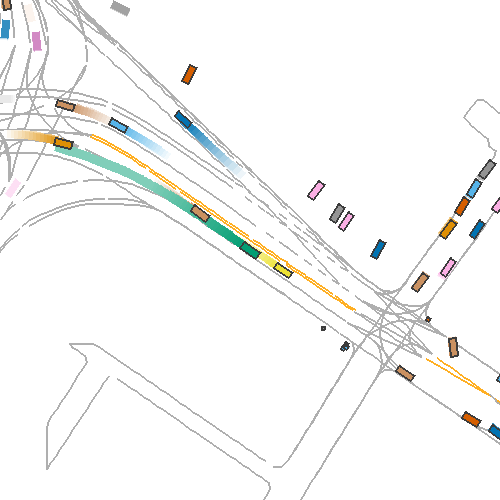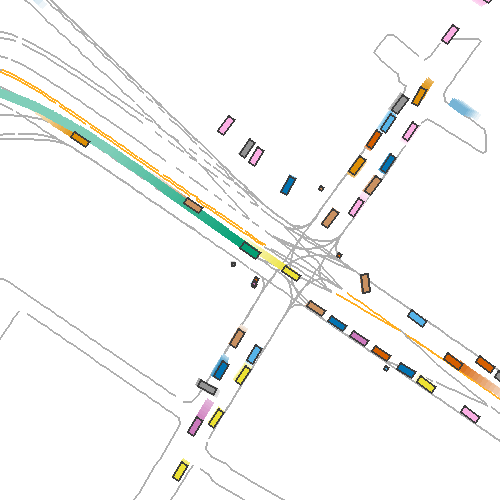
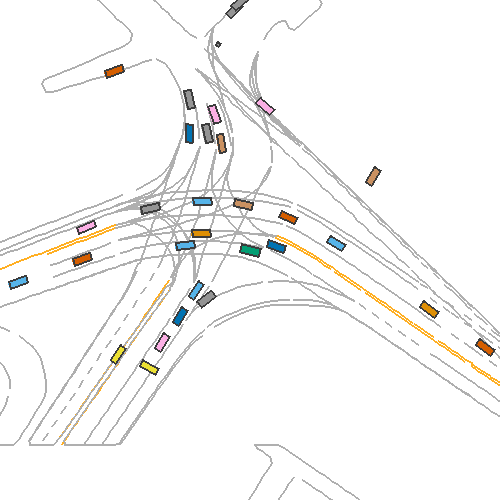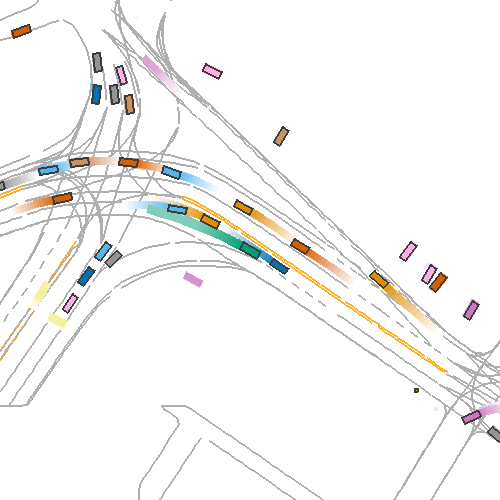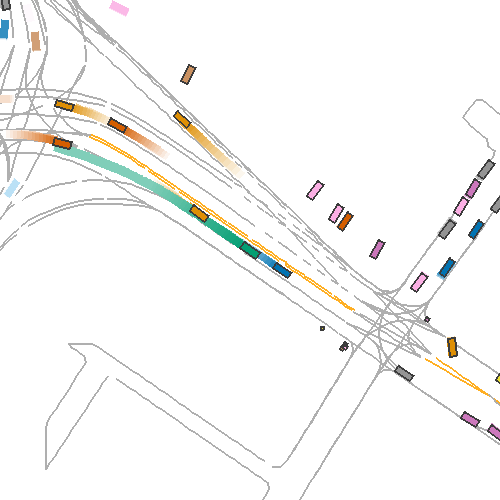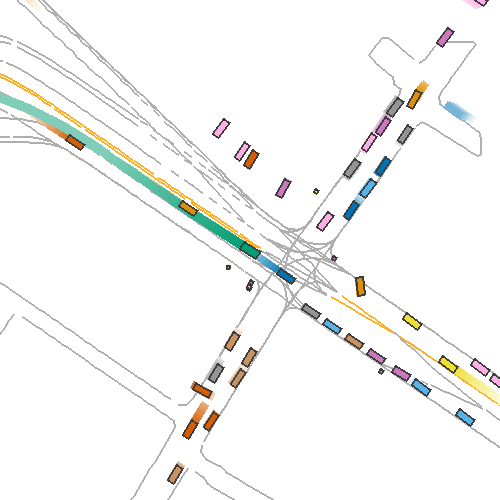
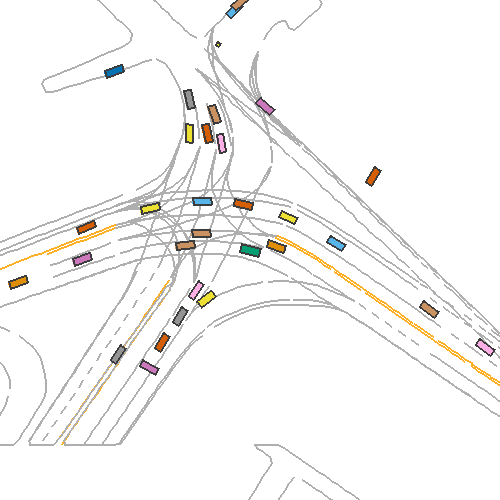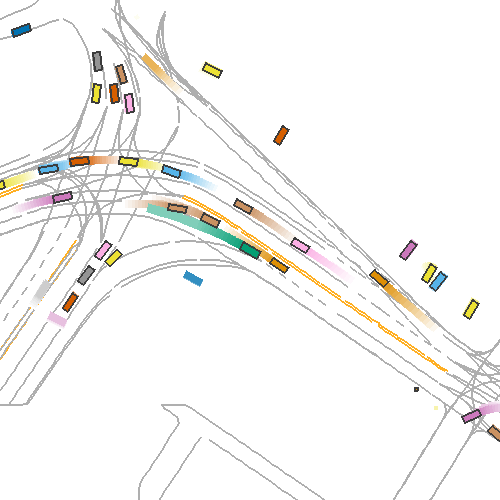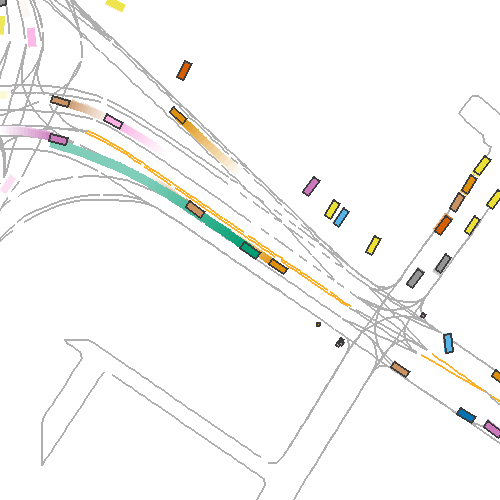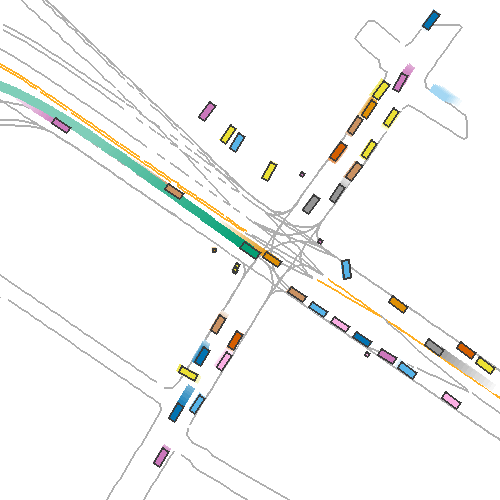
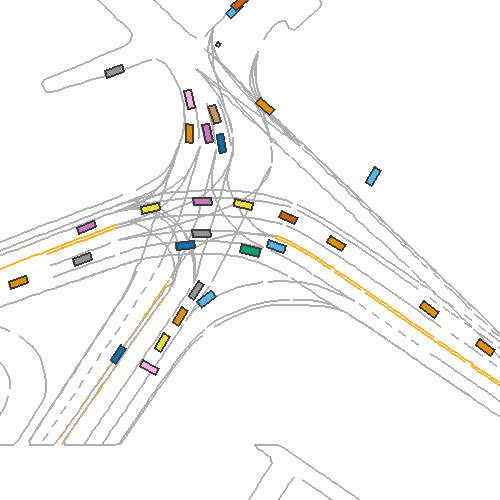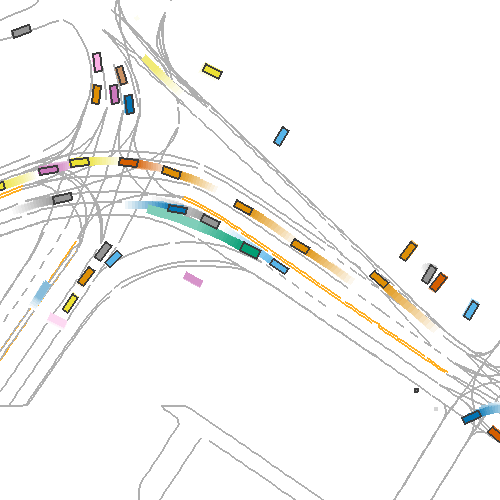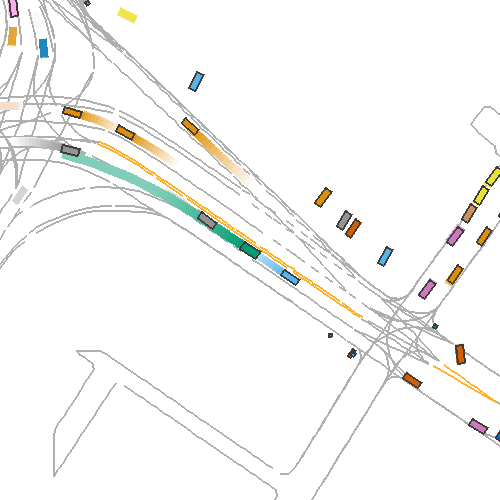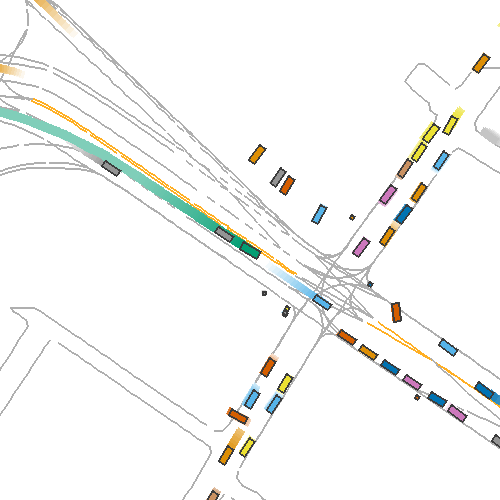
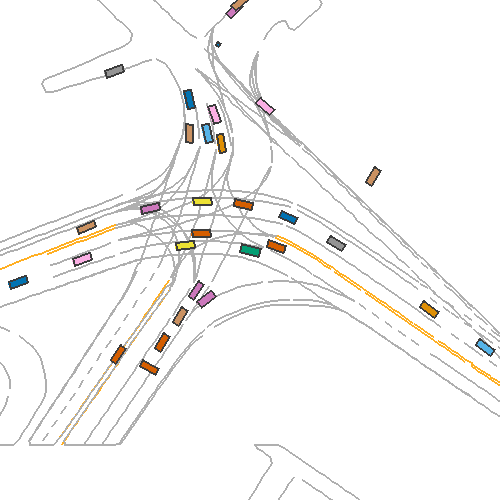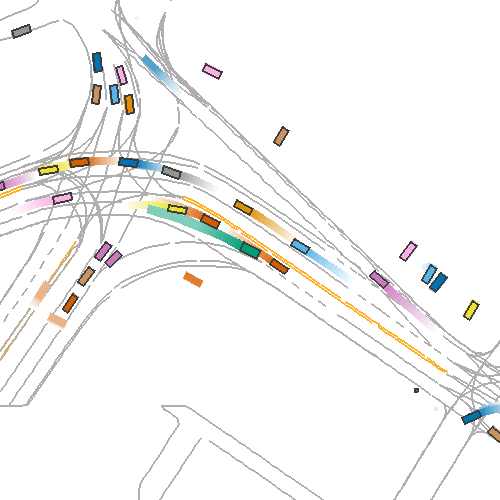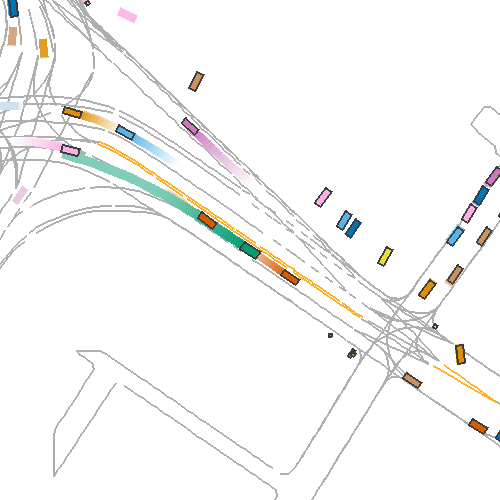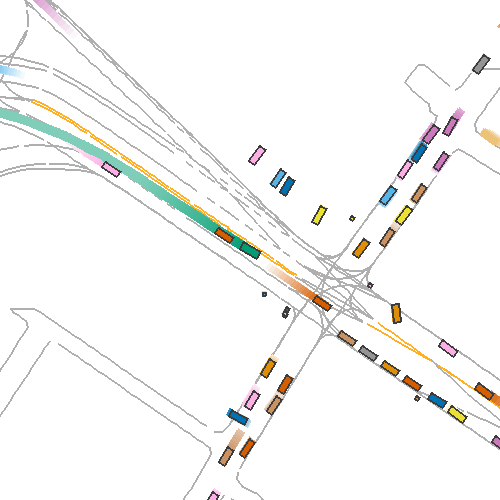
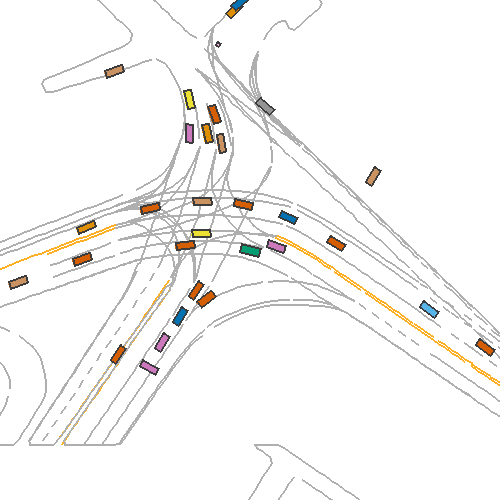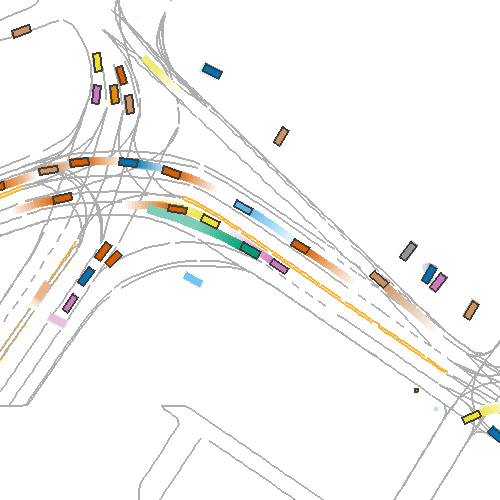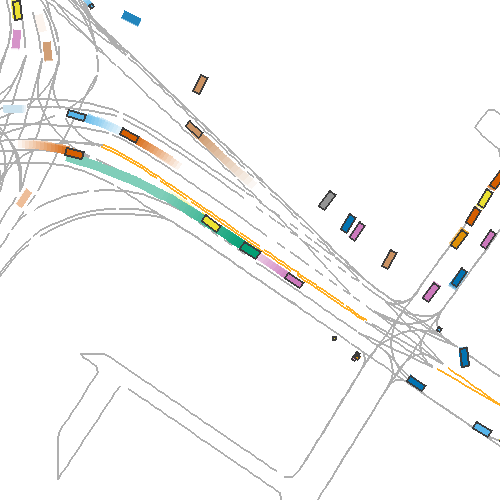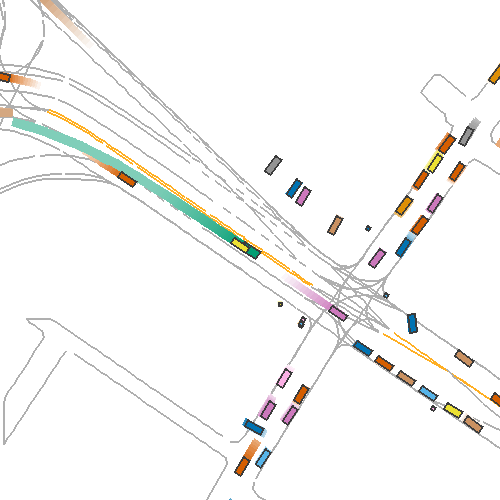
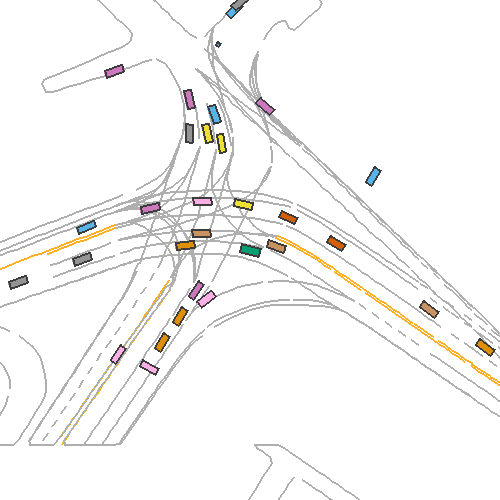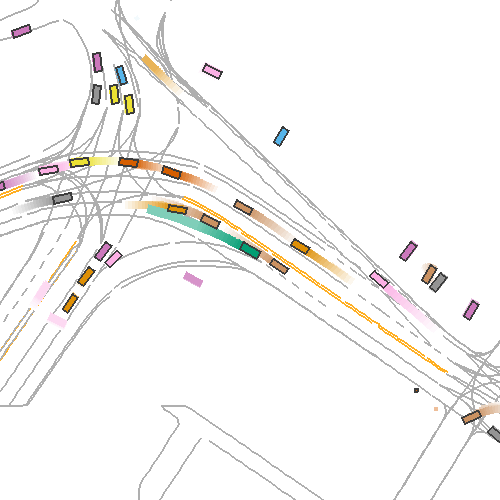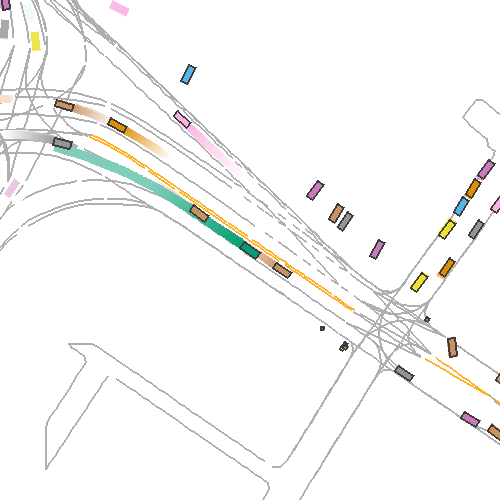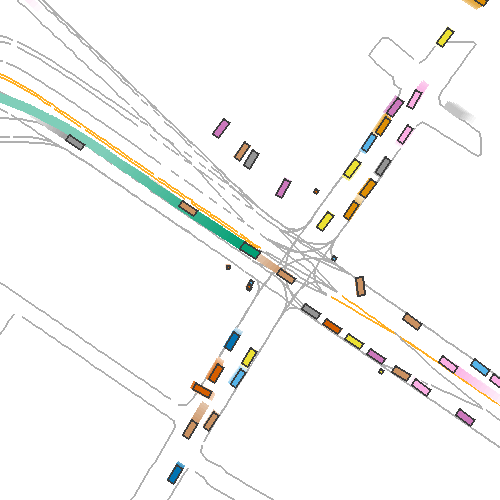
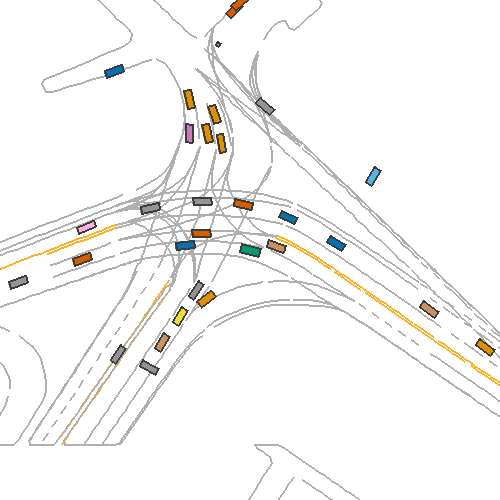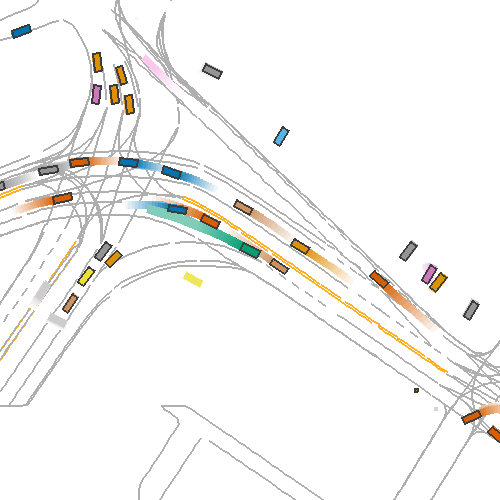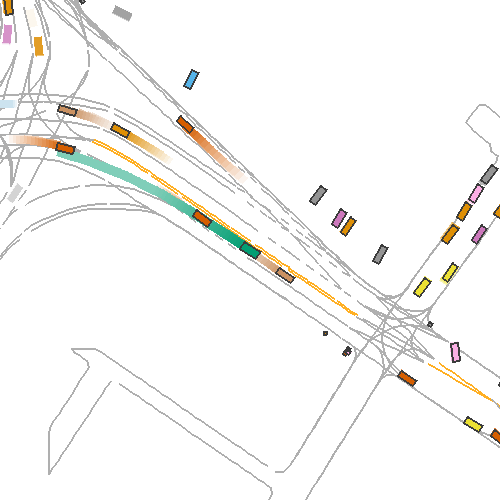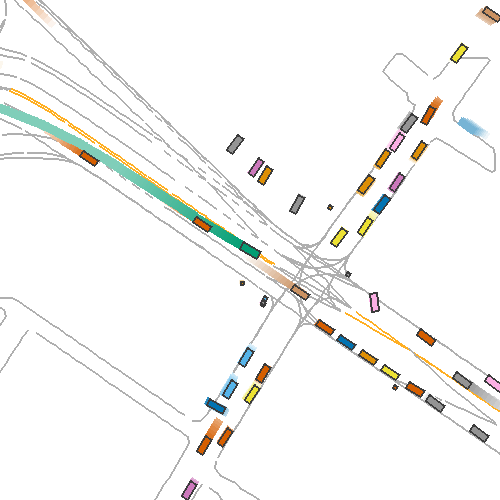
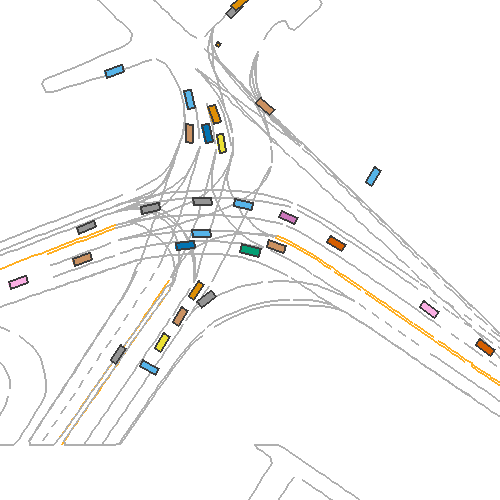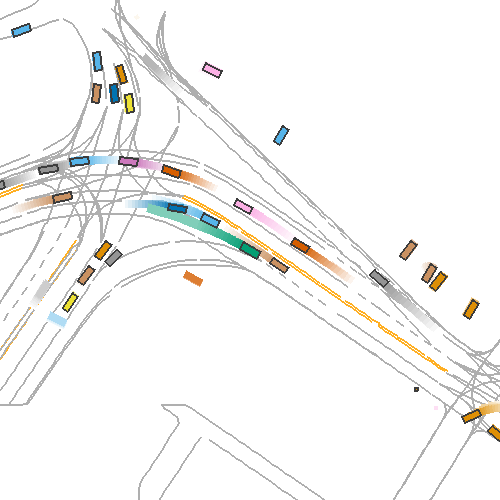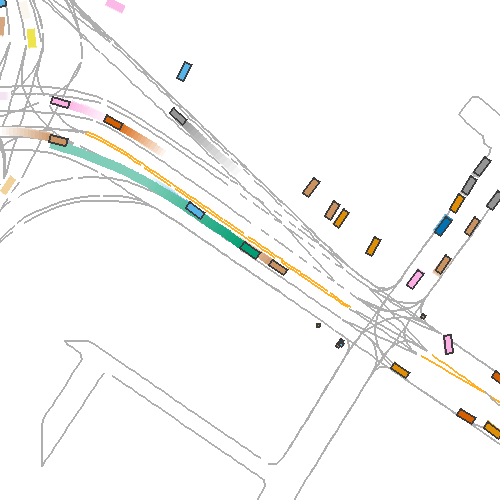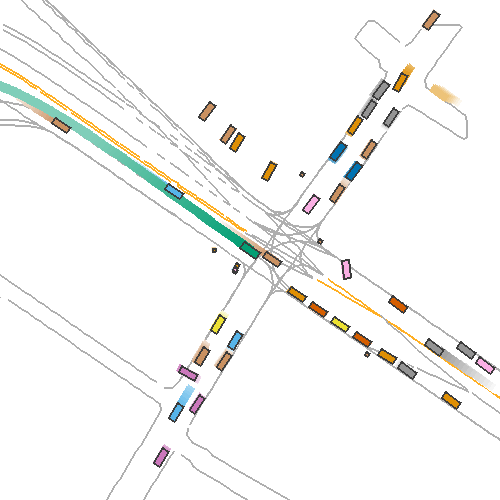
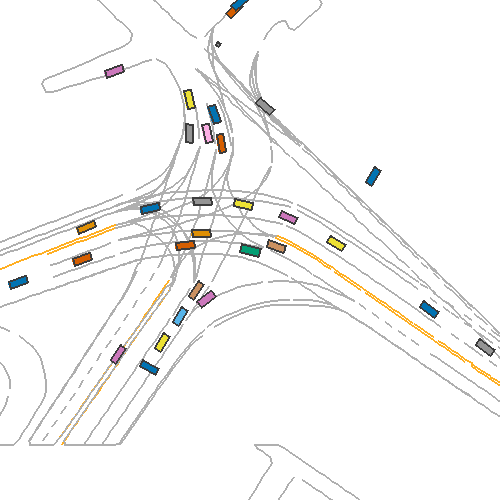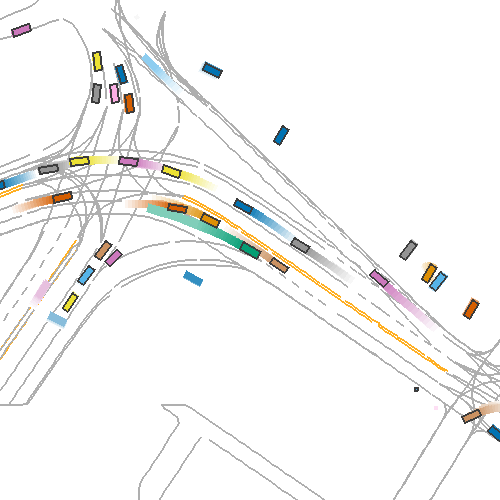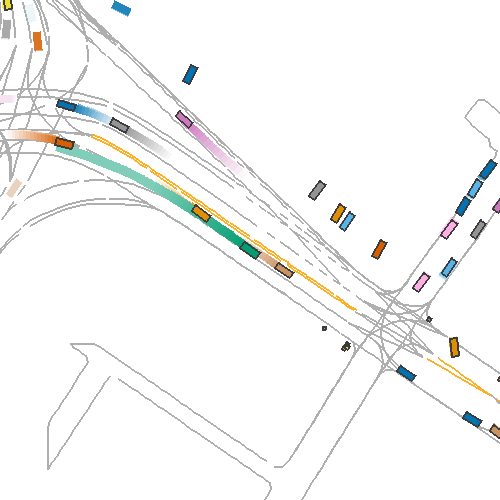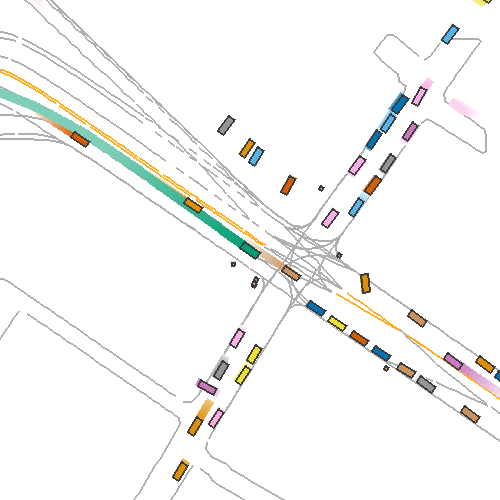
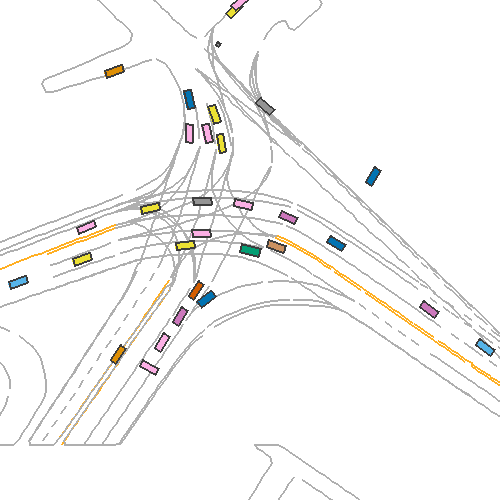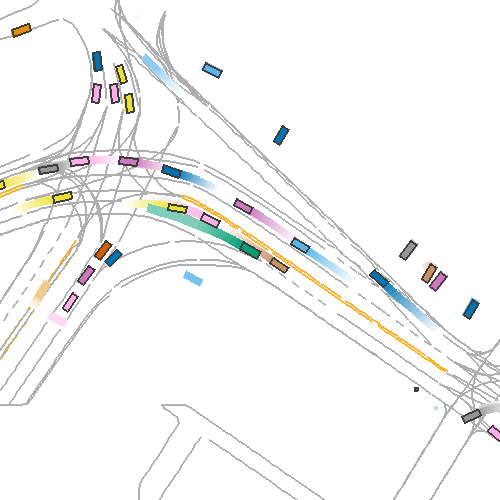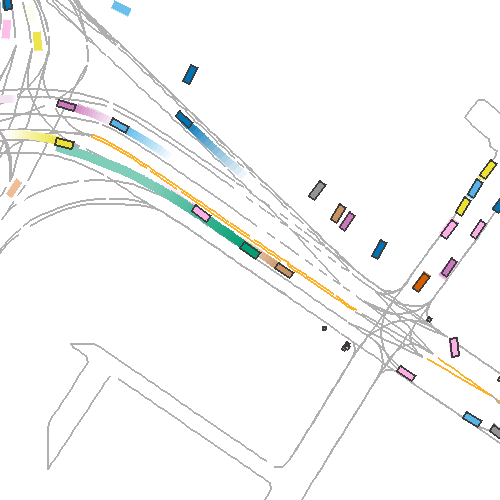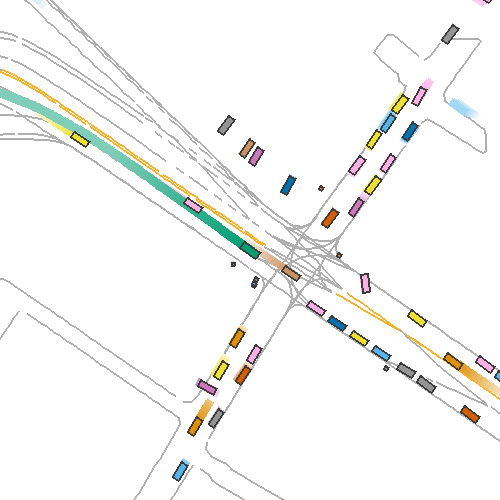
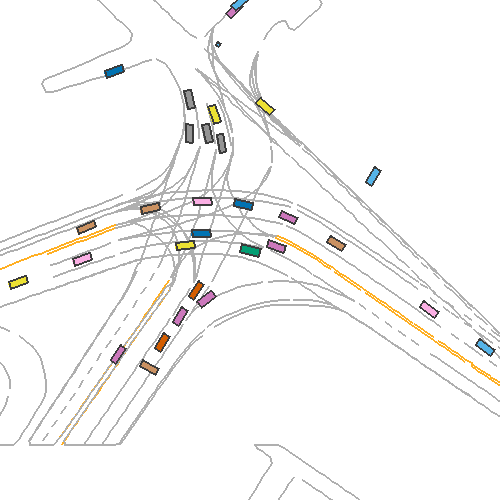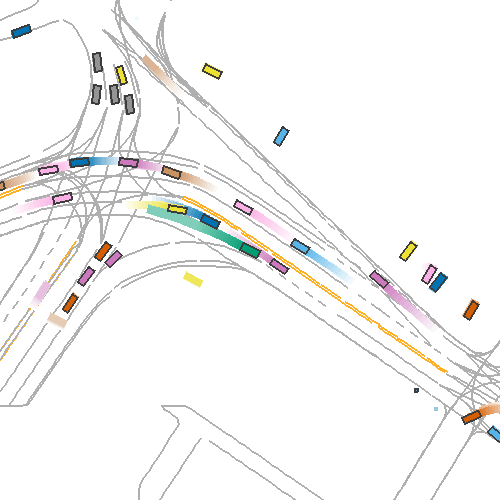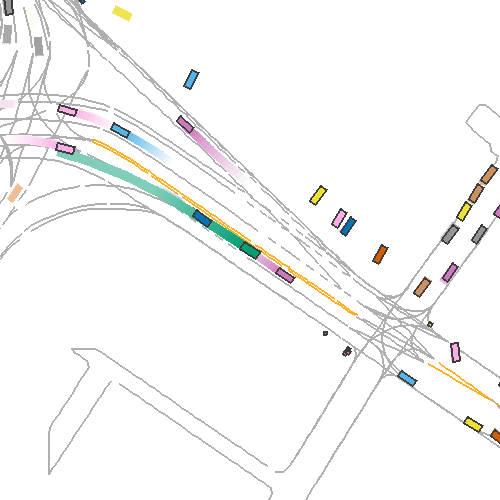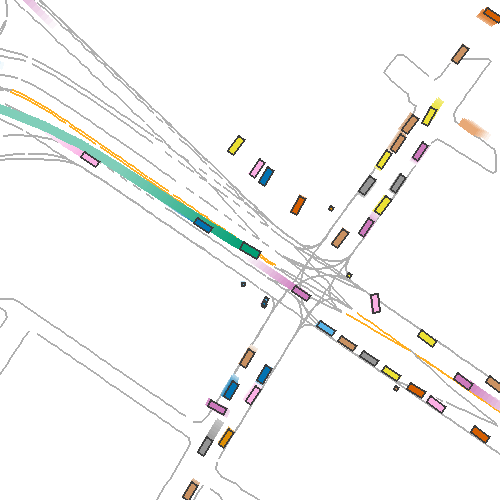
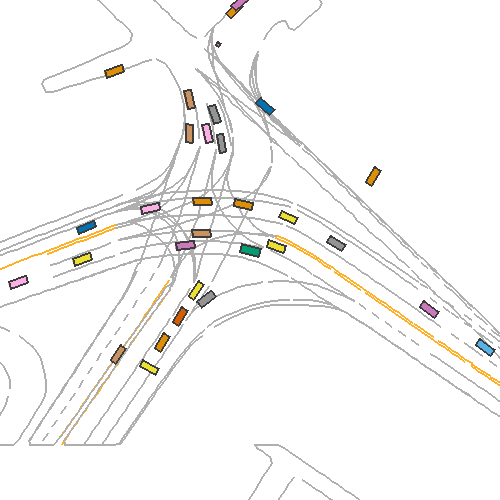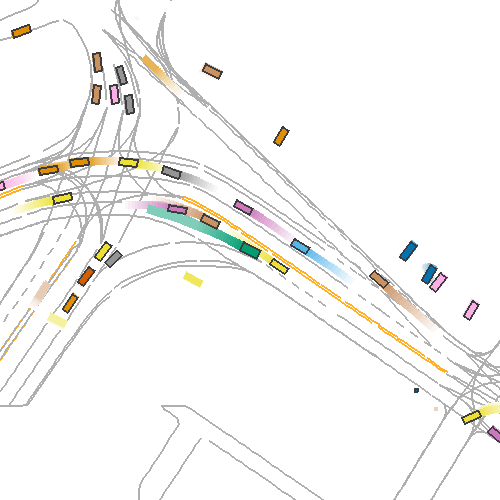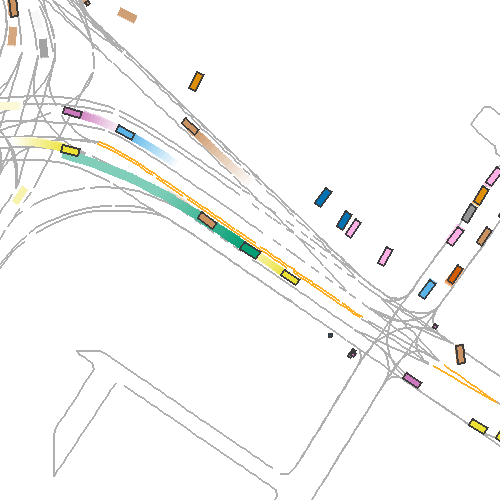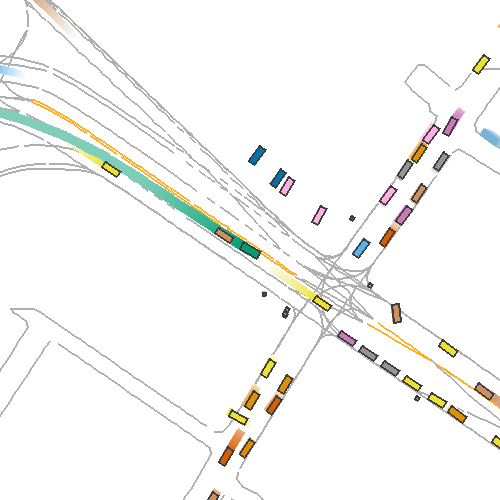
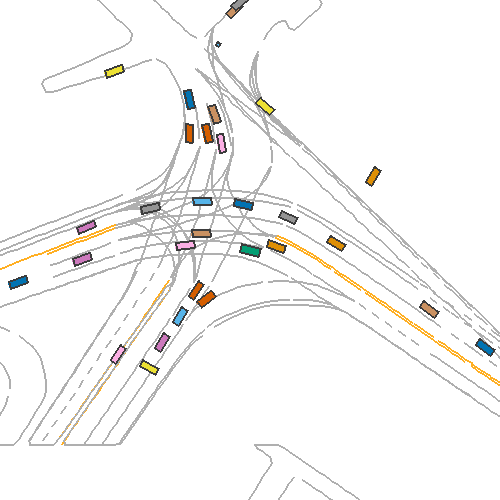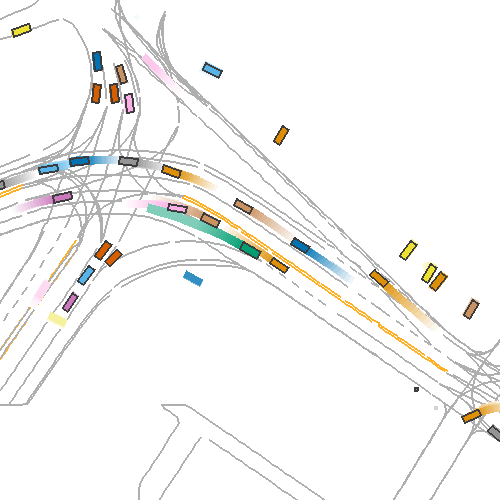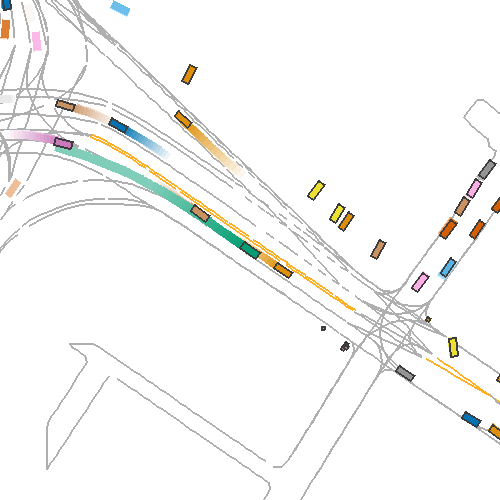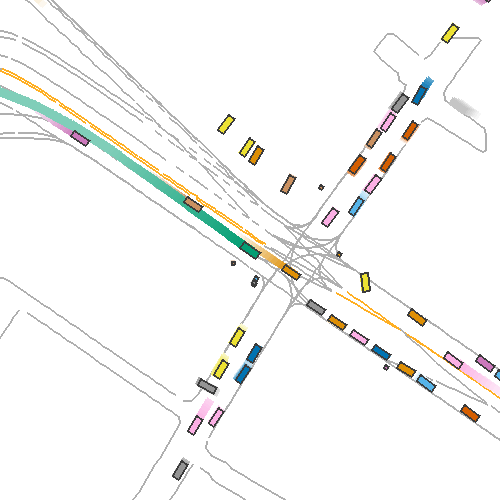
The vehicle being predicted is always colored green; other vehicles are following real-world log replays and are assigned random colors. The following predictions are open-loop only, meaning that nearby vehicles are not influenced by the predicted vehicle's behavior.
In each sample, we observe divergence in outcomes based on relative speed or headway. This is different from other works in simulation, which may involve divergence in outcomes based on intent.
@inproceedings{zheng2026polysona,
  title     = {Polysona: Modular Driving Styles in Trajectory Prediction},
  author    = {Zheng, Laura and Yaghoubi Araghi, Hamidreza and Wu, Tony and Zhou, Tianyi and Lin, Ming C.},
  booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  year      = {2026}
}